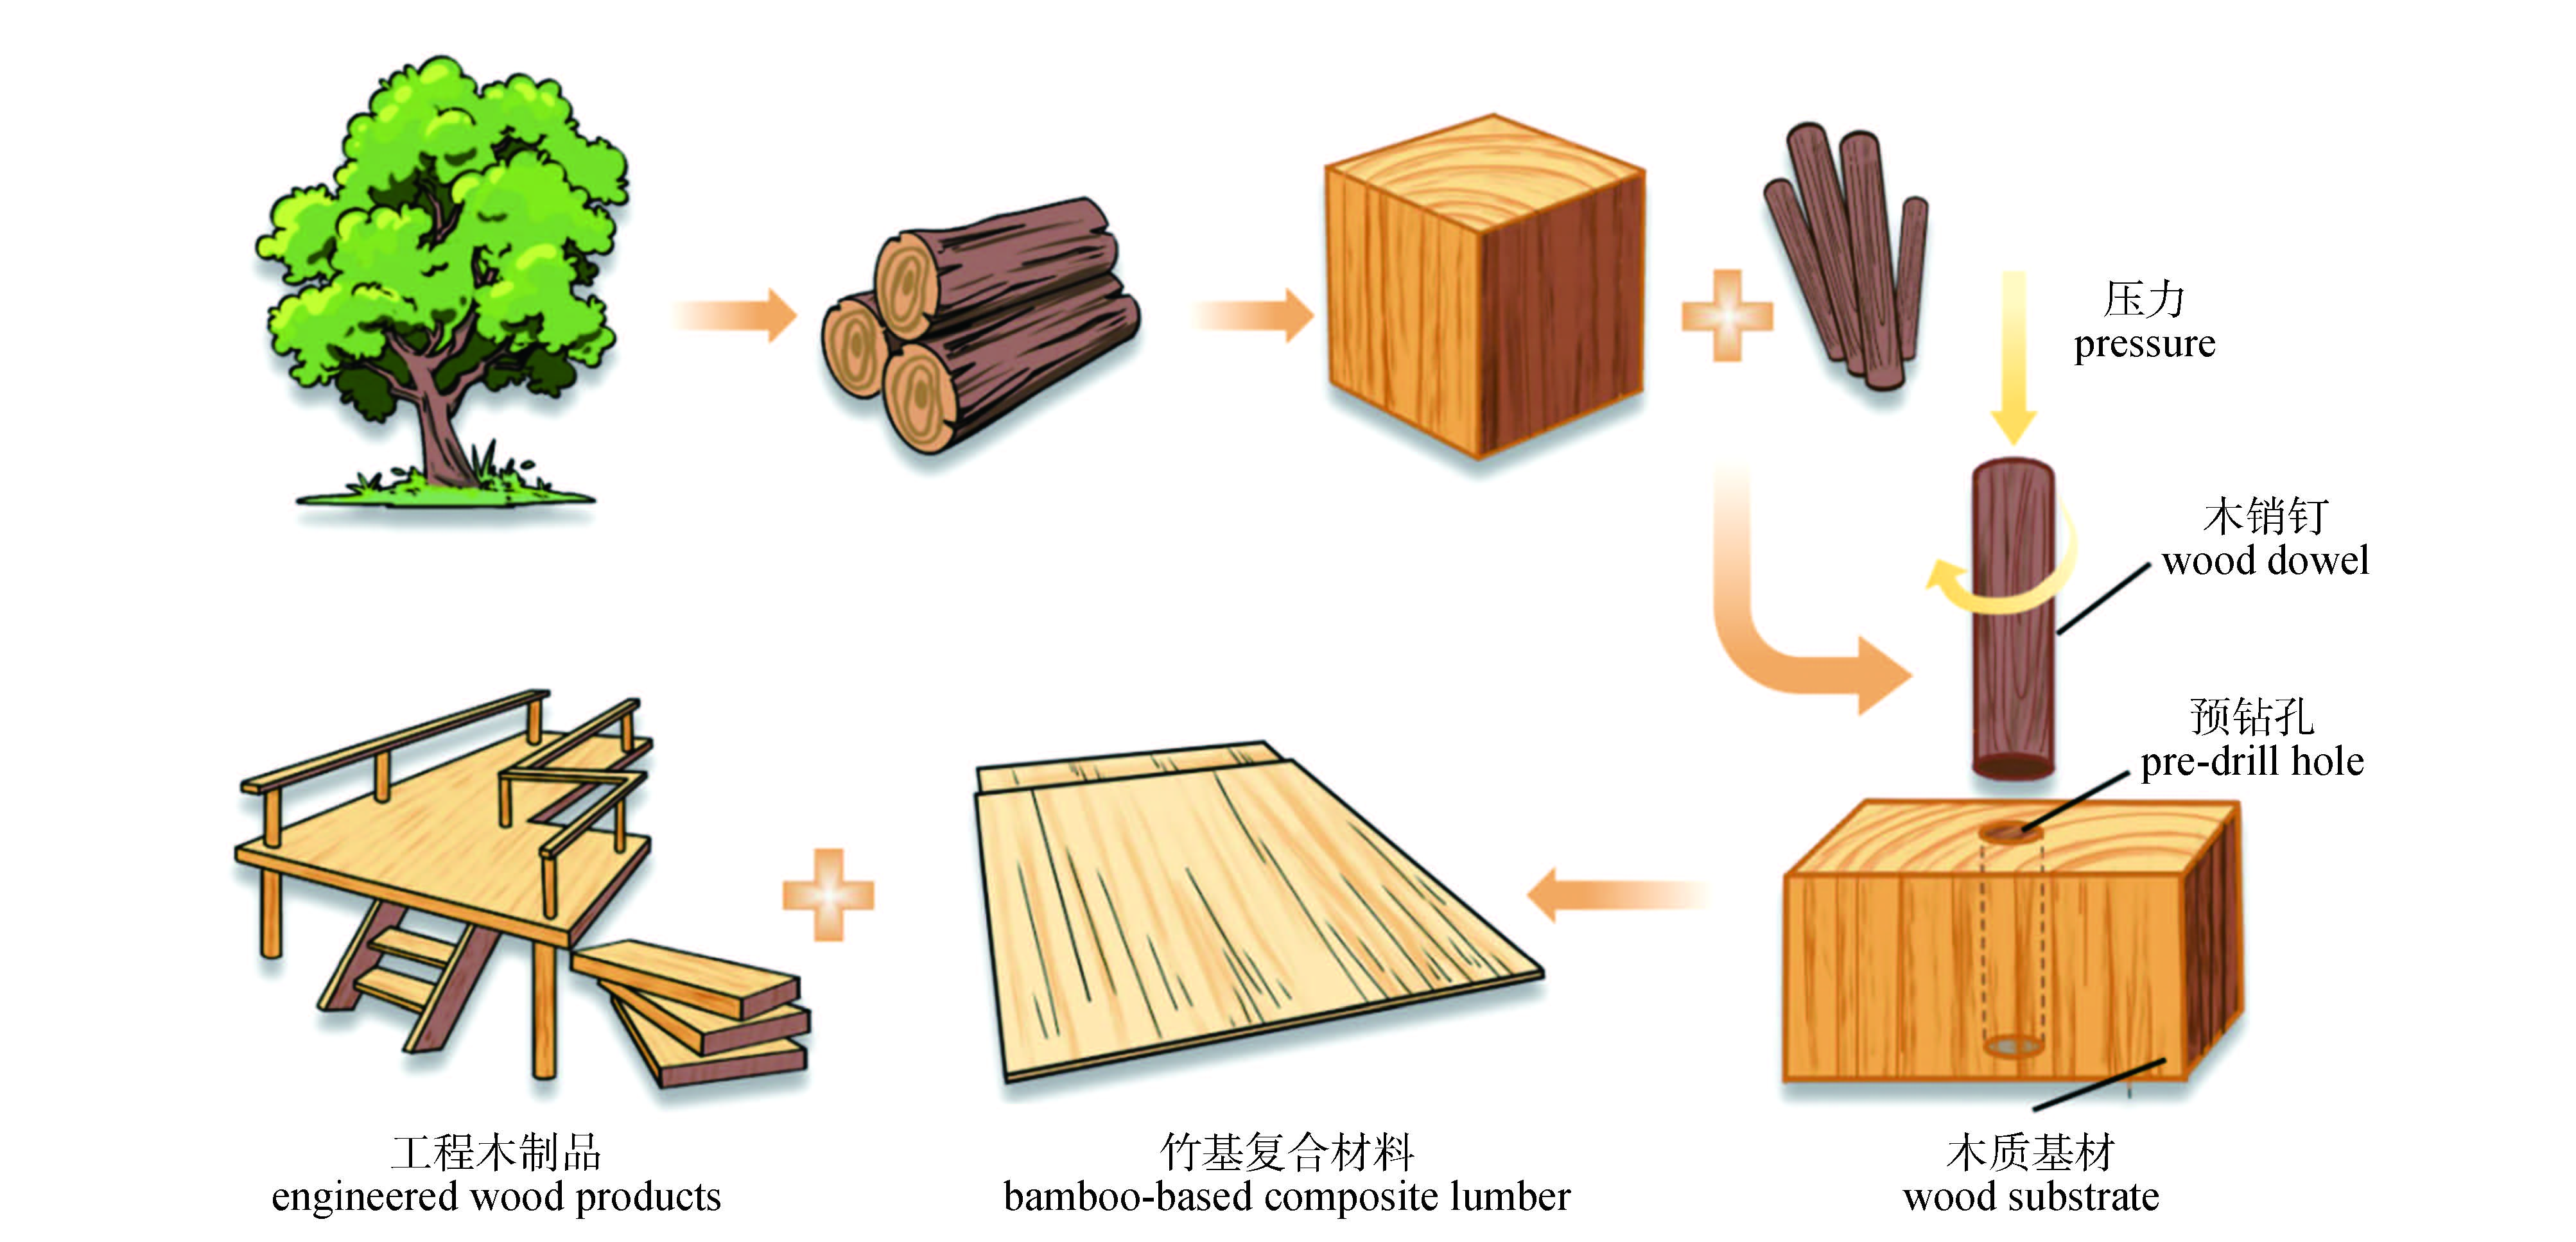
Rotational friction welding technology, as a bonding method that does not require chemical adhesives, has gradually become an important research direction in wood (bamboo) processing. This paper systematically reviews the reaction mechanisms of the welding process and key factors influencing weld strength. It analyzes the applicability of rotary friction welding in engineered wood products, concluding that this technology not only effectively enhances joint mechanical properties but also offers advantages such as reduced carbon emissions and improved material recyclability. It demonstrates promising application potential in engineered wood products like laminated dowel-jointed wood and glued laminated beams. Due to higher lignin content, bamboo also holds potential advantages in this technology, but still faces industrialization challenges such as high silica content and a narrow process window. It analyzes existing challenges in rotational friction welding applications, such as equipment unsuitability for industrial production and incomplete process parameter optimization. Recommendations include advancing the specialization and automation of rotational friction welding equipment, systematically optimizing welding performance and control parameters, and deepening research and industrial application of bamboo welding technology.
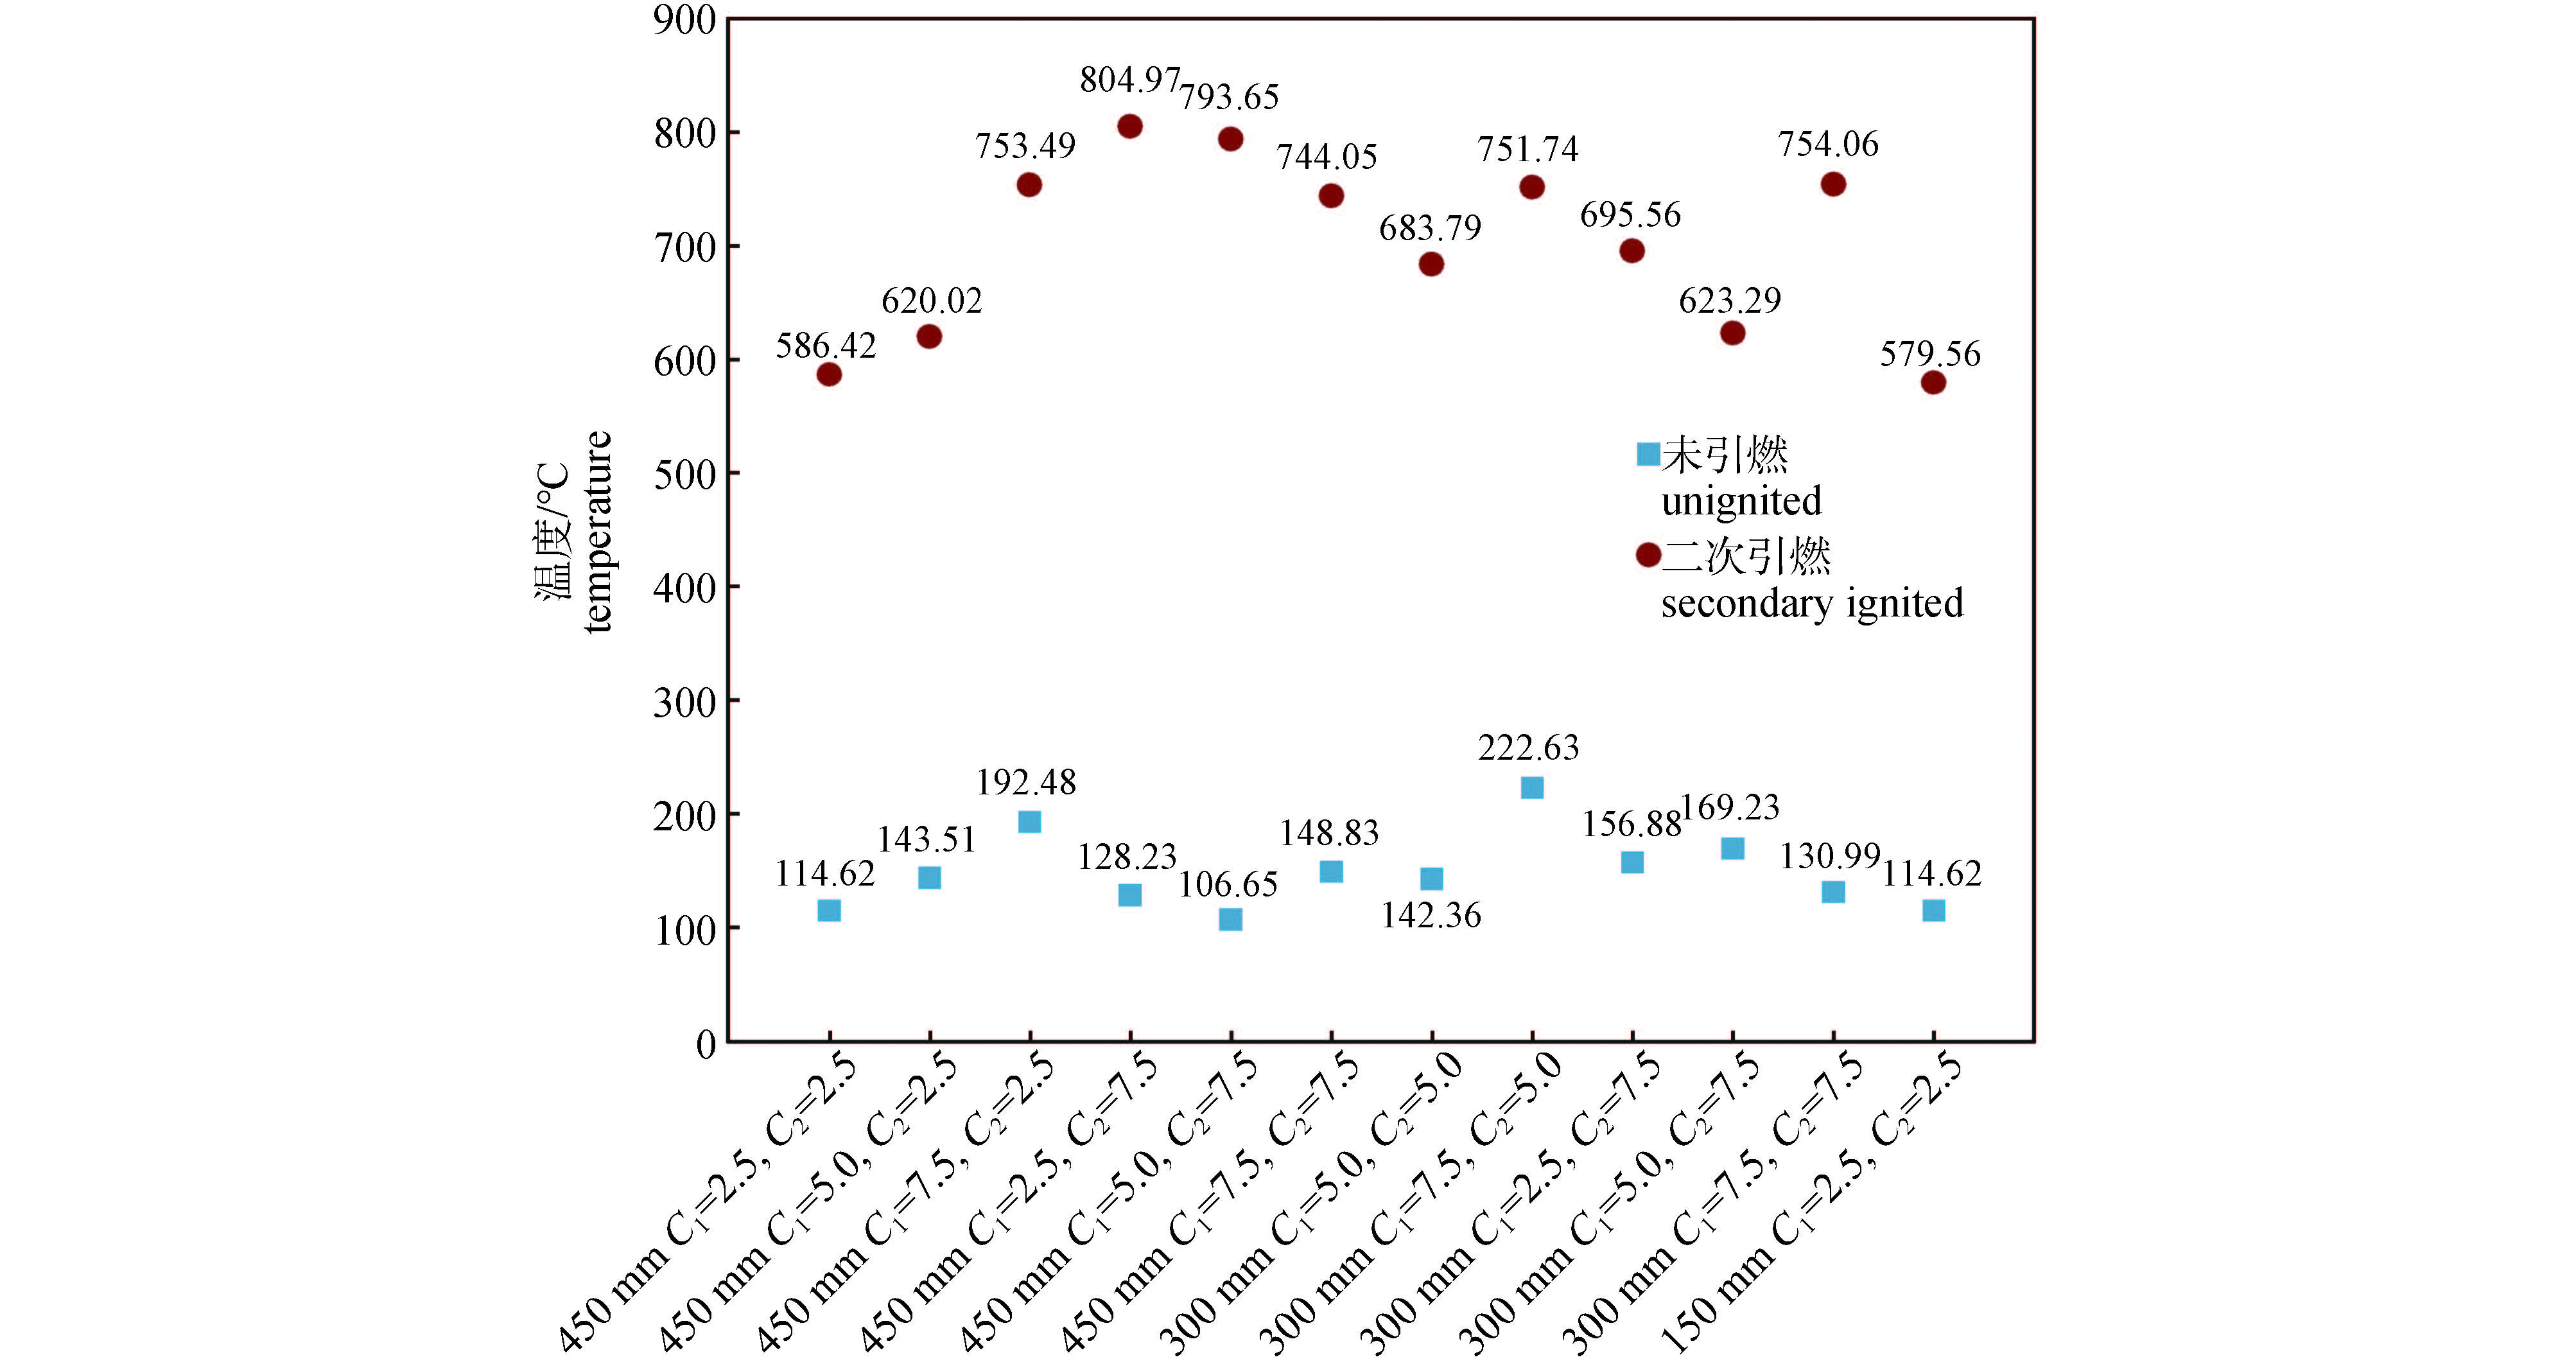
Crown fires are among the most destructive forest forms of wildland fire, however, their spread mechanisms within multi-layer canopy structures remain insufficiently understood. Therefore, this work focused on Pinus koraiensis plantation, characterized by high crow fire susceptibility. Through a series of controlled laboratory experiments, we investigated the coupled regulatory effects of horizontal canopy spacing and canopy bulk density on crown fire spread behavior and burning intensity in a dual-layer canopy system, with the aim of providing a theoretical basis for refined fire modeling and prevention strategies. Experiments were conducted in a wind-free indoor environment, and the research was carried out through controlled dual-layer canopy crown fire burning experiments. The primary variables were the bulk density loads of two canopies and the horizontal spacing between canopy elements, each examined at three gradient levels. A thermocouple array and heat flux sensors were deployed to simultaneously measure internal temperature fields, radiant heat flux density, and flame front arrival times. All experimental conditions were fully replicated, with surface fire spread and adiabatic configurations included as control groups for comparison. Under calm wind and laboratory small-scale conditions, the research results indicated that: (1) radiant heat transfer was the dominant mechanism for energy transfer between canopies (without direct flame contact), and the proportion of heat flow remained stable at 40%-46%. (2) There was a clear control mechanism transition in the system. As the spacing decreased, the fire spread processed transitions from fuel control to heat transfer control mechanism. (3) There was a clear temperature threshold for the ignition of the second canopy (250 ℃), and the front edge temperature can serve as an effective real-time prediction indicator. (4) The heat flux density of the first canopy had a nonlinear reinforcing effect on the overall fire behavior of the system. There was an optimal ratio and a clear overload critical value, and it weakened after exceeding the critical value. (5) Under the influence of the first canopy, the reignited second canopy showed a 50% probability of its temperature significantly exceeding the intensity ceiling of natural spread (up to 105.63 ℃ higher), achieving enhanced combustion performance. This illustrates hte complexity of crown fire as a multi factor systyem, indicating that any model aimed at precise prediction must take into account the nonlinear mechanisms of the interactions among the canopy structures.
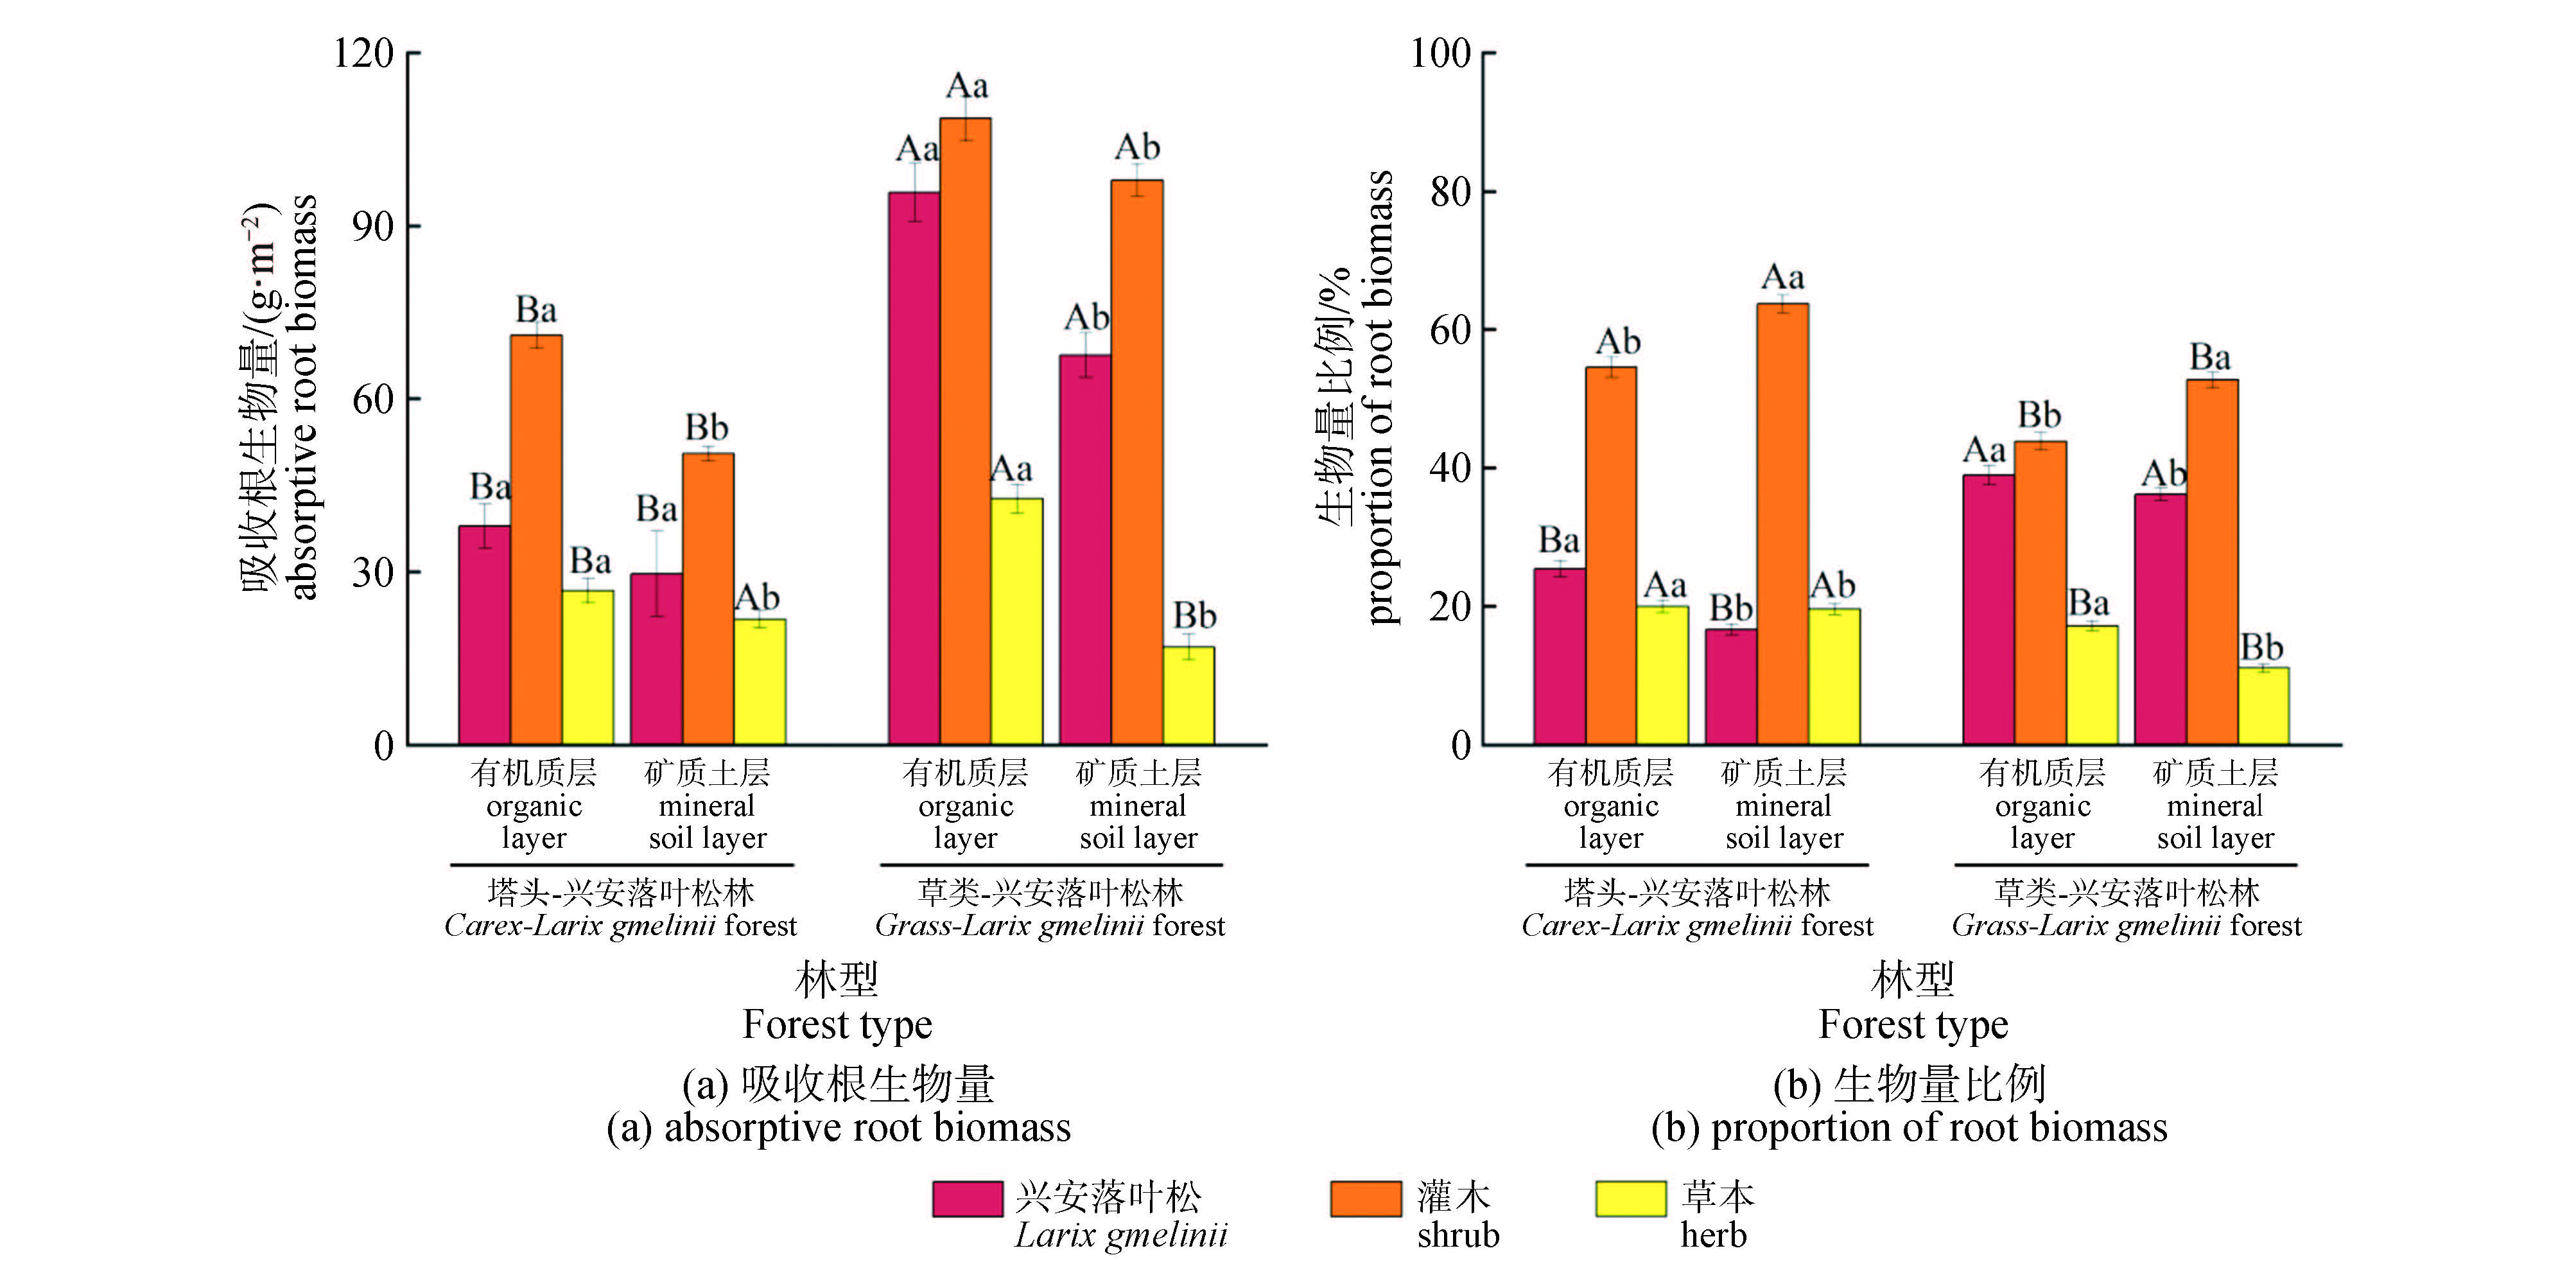
To reveal the variation characteristics of absorptive root morphology, biomass and root length density of plants with different life forms in two typical Larix gmelinii forest types, this study selected Carex-L.gmelinii forest and grass-L.gmelinii forest in Hongwei Forest Farm, Huzhong District of the Greater Khingan Mountains. The soil core method was adopted to determine the absorptive root morphology, biomass and root length density of L. gmelinii, understory shrubs and herbs in the organic layer and mineral soil layer, and the relationships between root characteristics of L.gmelinii and soil factors were further analyzed. The results showed that soil layer, forest type and life form all significantly affected absorptive root characteristics (P<0.05). In the two forest types, the absorptive root diameter of plants with three life forms in the organic layer was significantly lower than that in the mineral soil layer, while the specific root length showed an opposite trend. Between different forest types, the absorptive root morphology of three life forms differed significantly in the organic layer. In Carex-L.gmelinii forest, the specific root length of L.gmelinii was remarkably higher than that in grass-L.gmelinii forest, whereas the root tissue density was significantly lower than those in the grass-L.gmelinii forest. For understory vegetation, the absorptive root diameter of shrubs in grass-L.gmelinii forest was notably greater than that in Carex-L.gmelinii forest. In terms of root biomass and root length density, for all life forms in both forest types, the organic layer was significantly higher than the mineral soil layer, and the grass-L.gmelinii forest was significantly higher than the Carex-L.gmelinii forest. For biomass and root length density proportions, shrubs had the highest absorptive root biomass in both forest types. Correlation analysis indicated that the effects of soil factors on L.gmelinii absorptive roots differed between soil layers. Soil water content and total phosphorus were the main influencing factors in the organic layer, whereas total carbon, total nitrogen, carbon-to-nitrogen ratio, and total phosphorus were the key factors in the mineral soil layer. In conclusion, the characteristics of absorptive roots of L.gmelinii, understory herbs, and shrubs varies among forest types and soil layers, and soil factors exert differential effects on the absorptive root traits of L.gmelinii, which sheds light on the mechanistic understanding in species coexistence and diversity maintenance in this region.
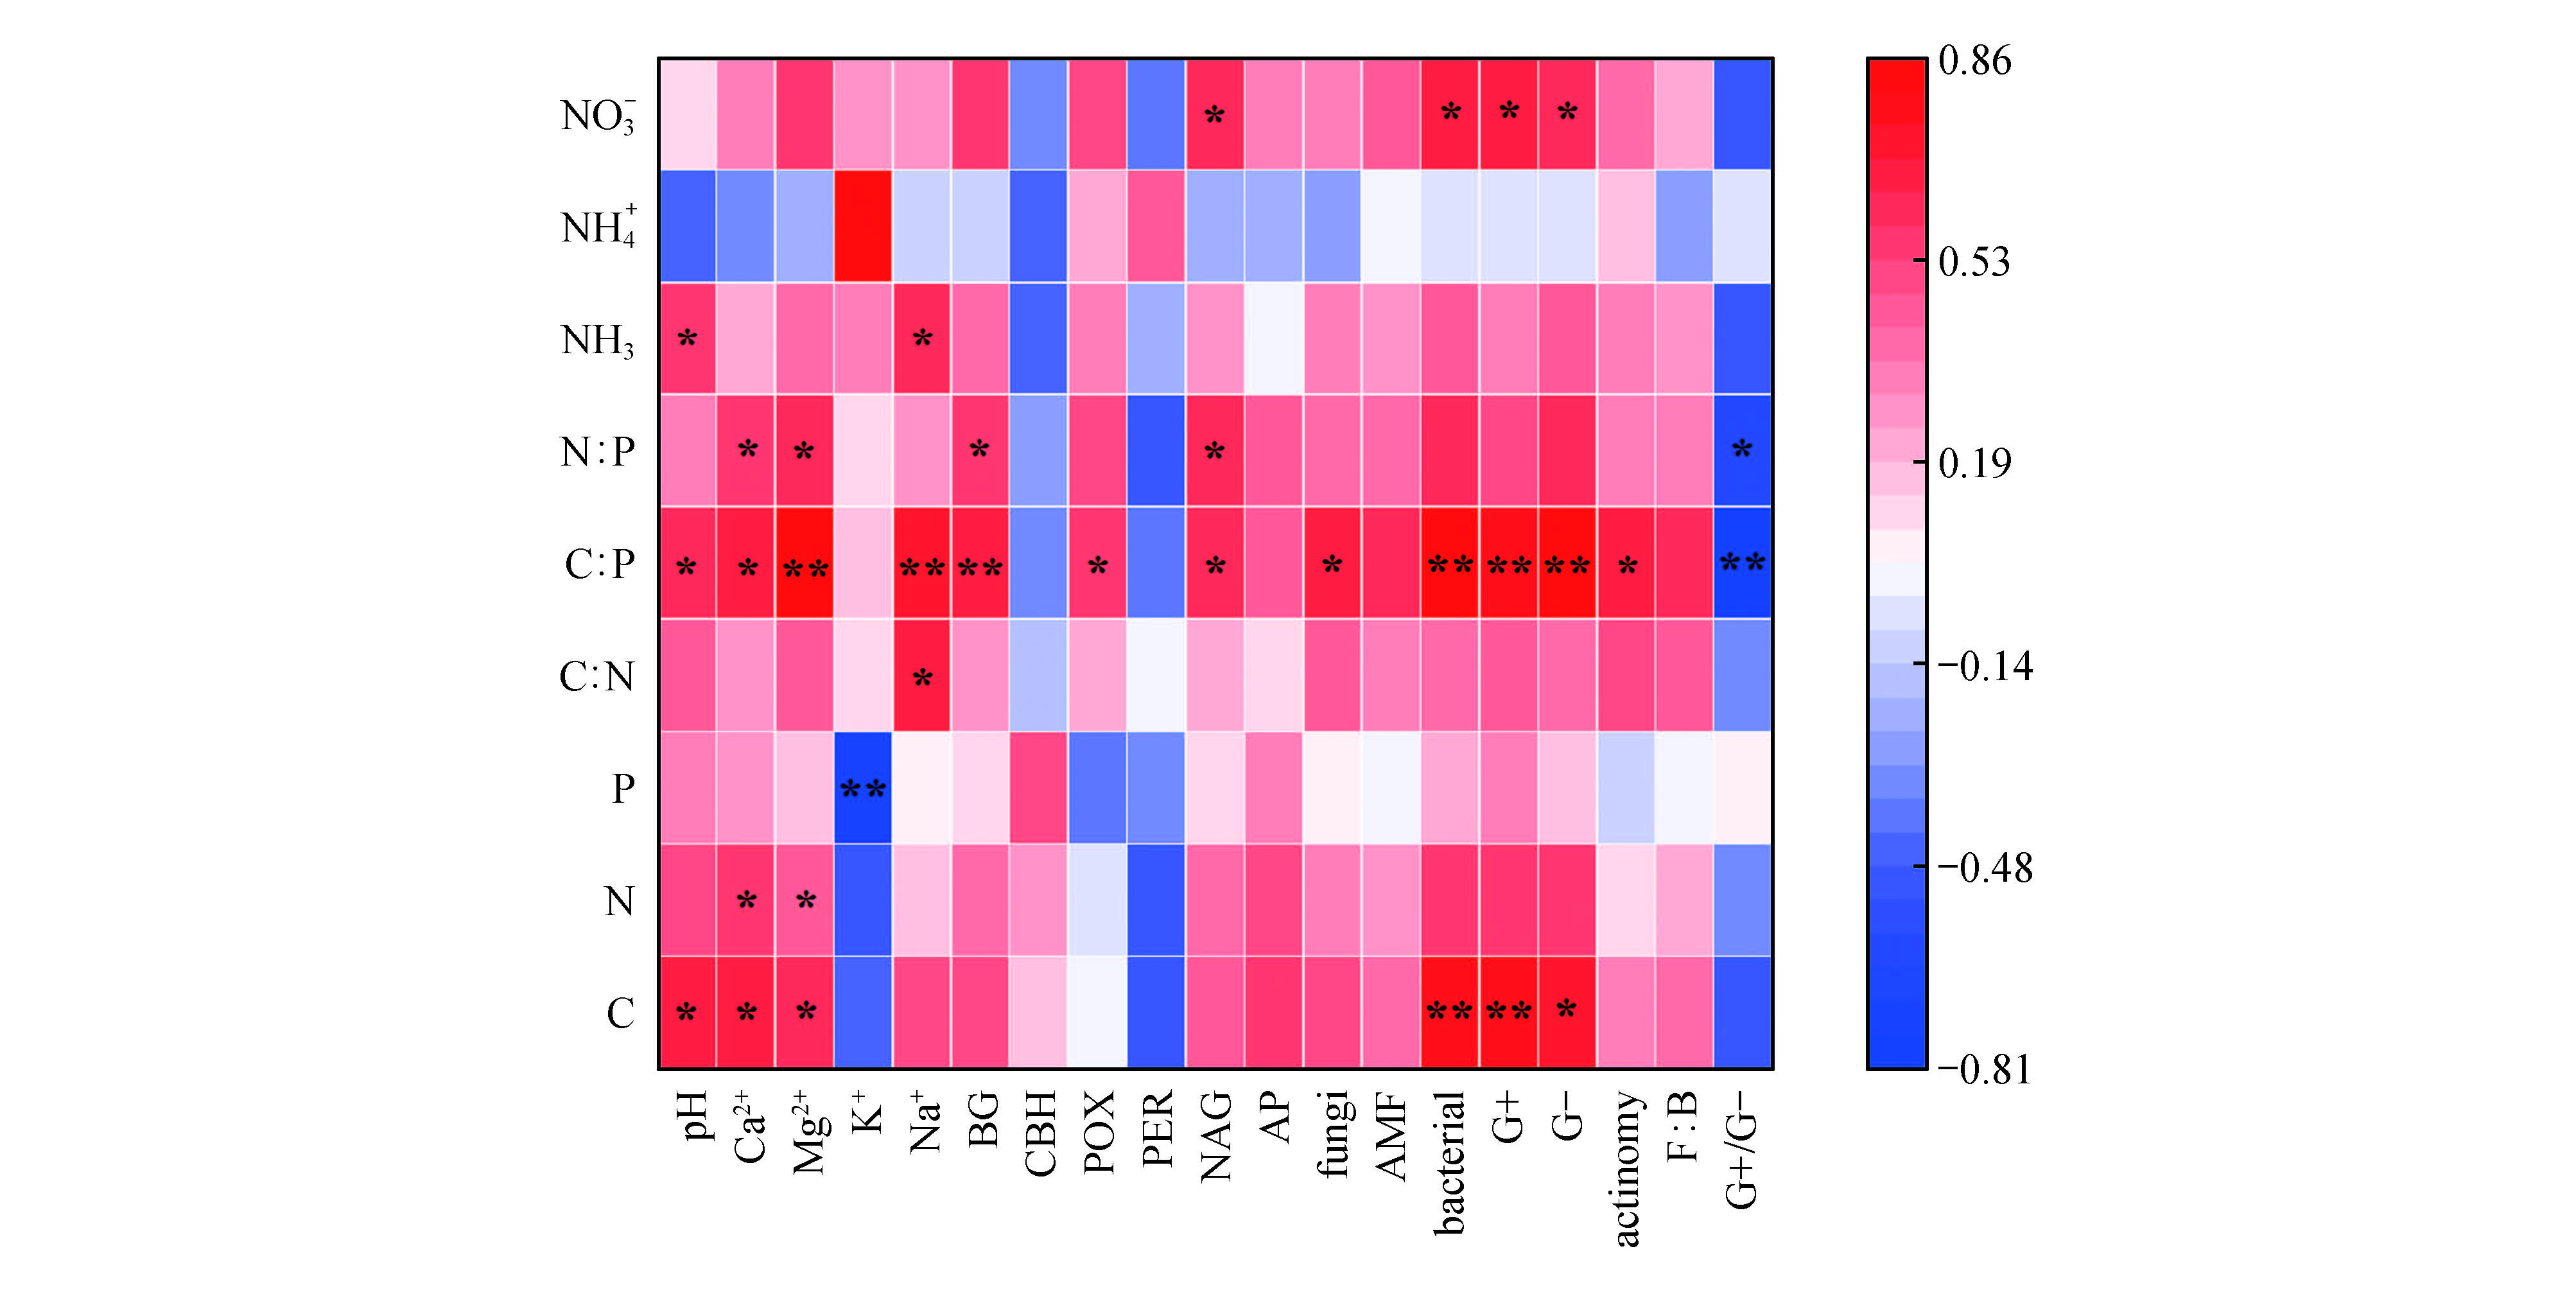
To assess the differential effects of major afforestation species on soil chemical and biological properties in windbreak and sand-fixation forests of the Horqin Sandy Land, this study examined 19-year-old plantations of Pinus sylvestris var. mongolica, Pinus tabuliformis, and Populus xiaozhuanica in the Zhanggutai region. Soil chemical and biological indicators were analyzed to determine interspecific variation and their correlations. The results revealed that in the 0-20 cm soil layer, the soil Mg2+ concentration in P.xiaozhuanica was significantly higher than in P.sylvestris var. mongolica plantations by 43.88%. The Na+ concentration was 4.40 times and 2.87 times that of P.sylvestris var. mongolica and P.tabuliformis plantations, with significant differences (P<0.05). The C:P ratio was significantly higher than in P.sylvestris var. mongolica plantations by 23.39%. The β-glucosidase activity was significantly higher than in P.sylvestris var. mongolica and P.tabuliformis plantations by 78.17% and 89.02%. The N-acetylglucosaminidase activity was 2.16 times that of P.sylvestris var. mongolica plantations, with significant differences (P<0.05). The bacterial biomass was significantly higher than in P.sylvestris var. mongolica plantations by 42.30%, and the gram-negative bacterial biomass was significantly higher than that in P.sylvestris var. mongolica and P.tabuliformis plantations by 69.55% and 61.47%, respectively. In the same layer, the soil cellulase hydrolysis activity and peroxidase activity in P.sylvestris var. mongolica plantations were 2.00 times and 1.58 times that of Populus xiaozhuanica plantations, with significant differences(P<0.05). In the 20-60 cm soil layer, soil organic carbon storage and mineral-associated organic carbon storage in Populus xiaozhuanica were significantly higher than in P.sylvestris var. mongolica plantations by 53.47%- 54.97% and 59.08%-62.55%, respectively. In the 60-100 cm layer, the soil organic carbon storage in P.sylvestris var. mongolica plantations was 2.55 times that of Populus xiaozhuanica plantations, with significant difference(P<0.05). By delving into the differential impacts of various forest types on soil chemical and biological properties, this study reveals that the soil C:P ratio in sandy lands serves as a critical factor explaining the functionality of soil microbial communities. Populus xiaozhuanica plantations significantly enhance the fertility of surface soil, while P.sylvestris var. mongolica plantations demonstrate greater advantages in long-term carbon sequestration within deeper soil layers. Different tree species can thus be rationally allocated based on specific ecological restoration objectives.
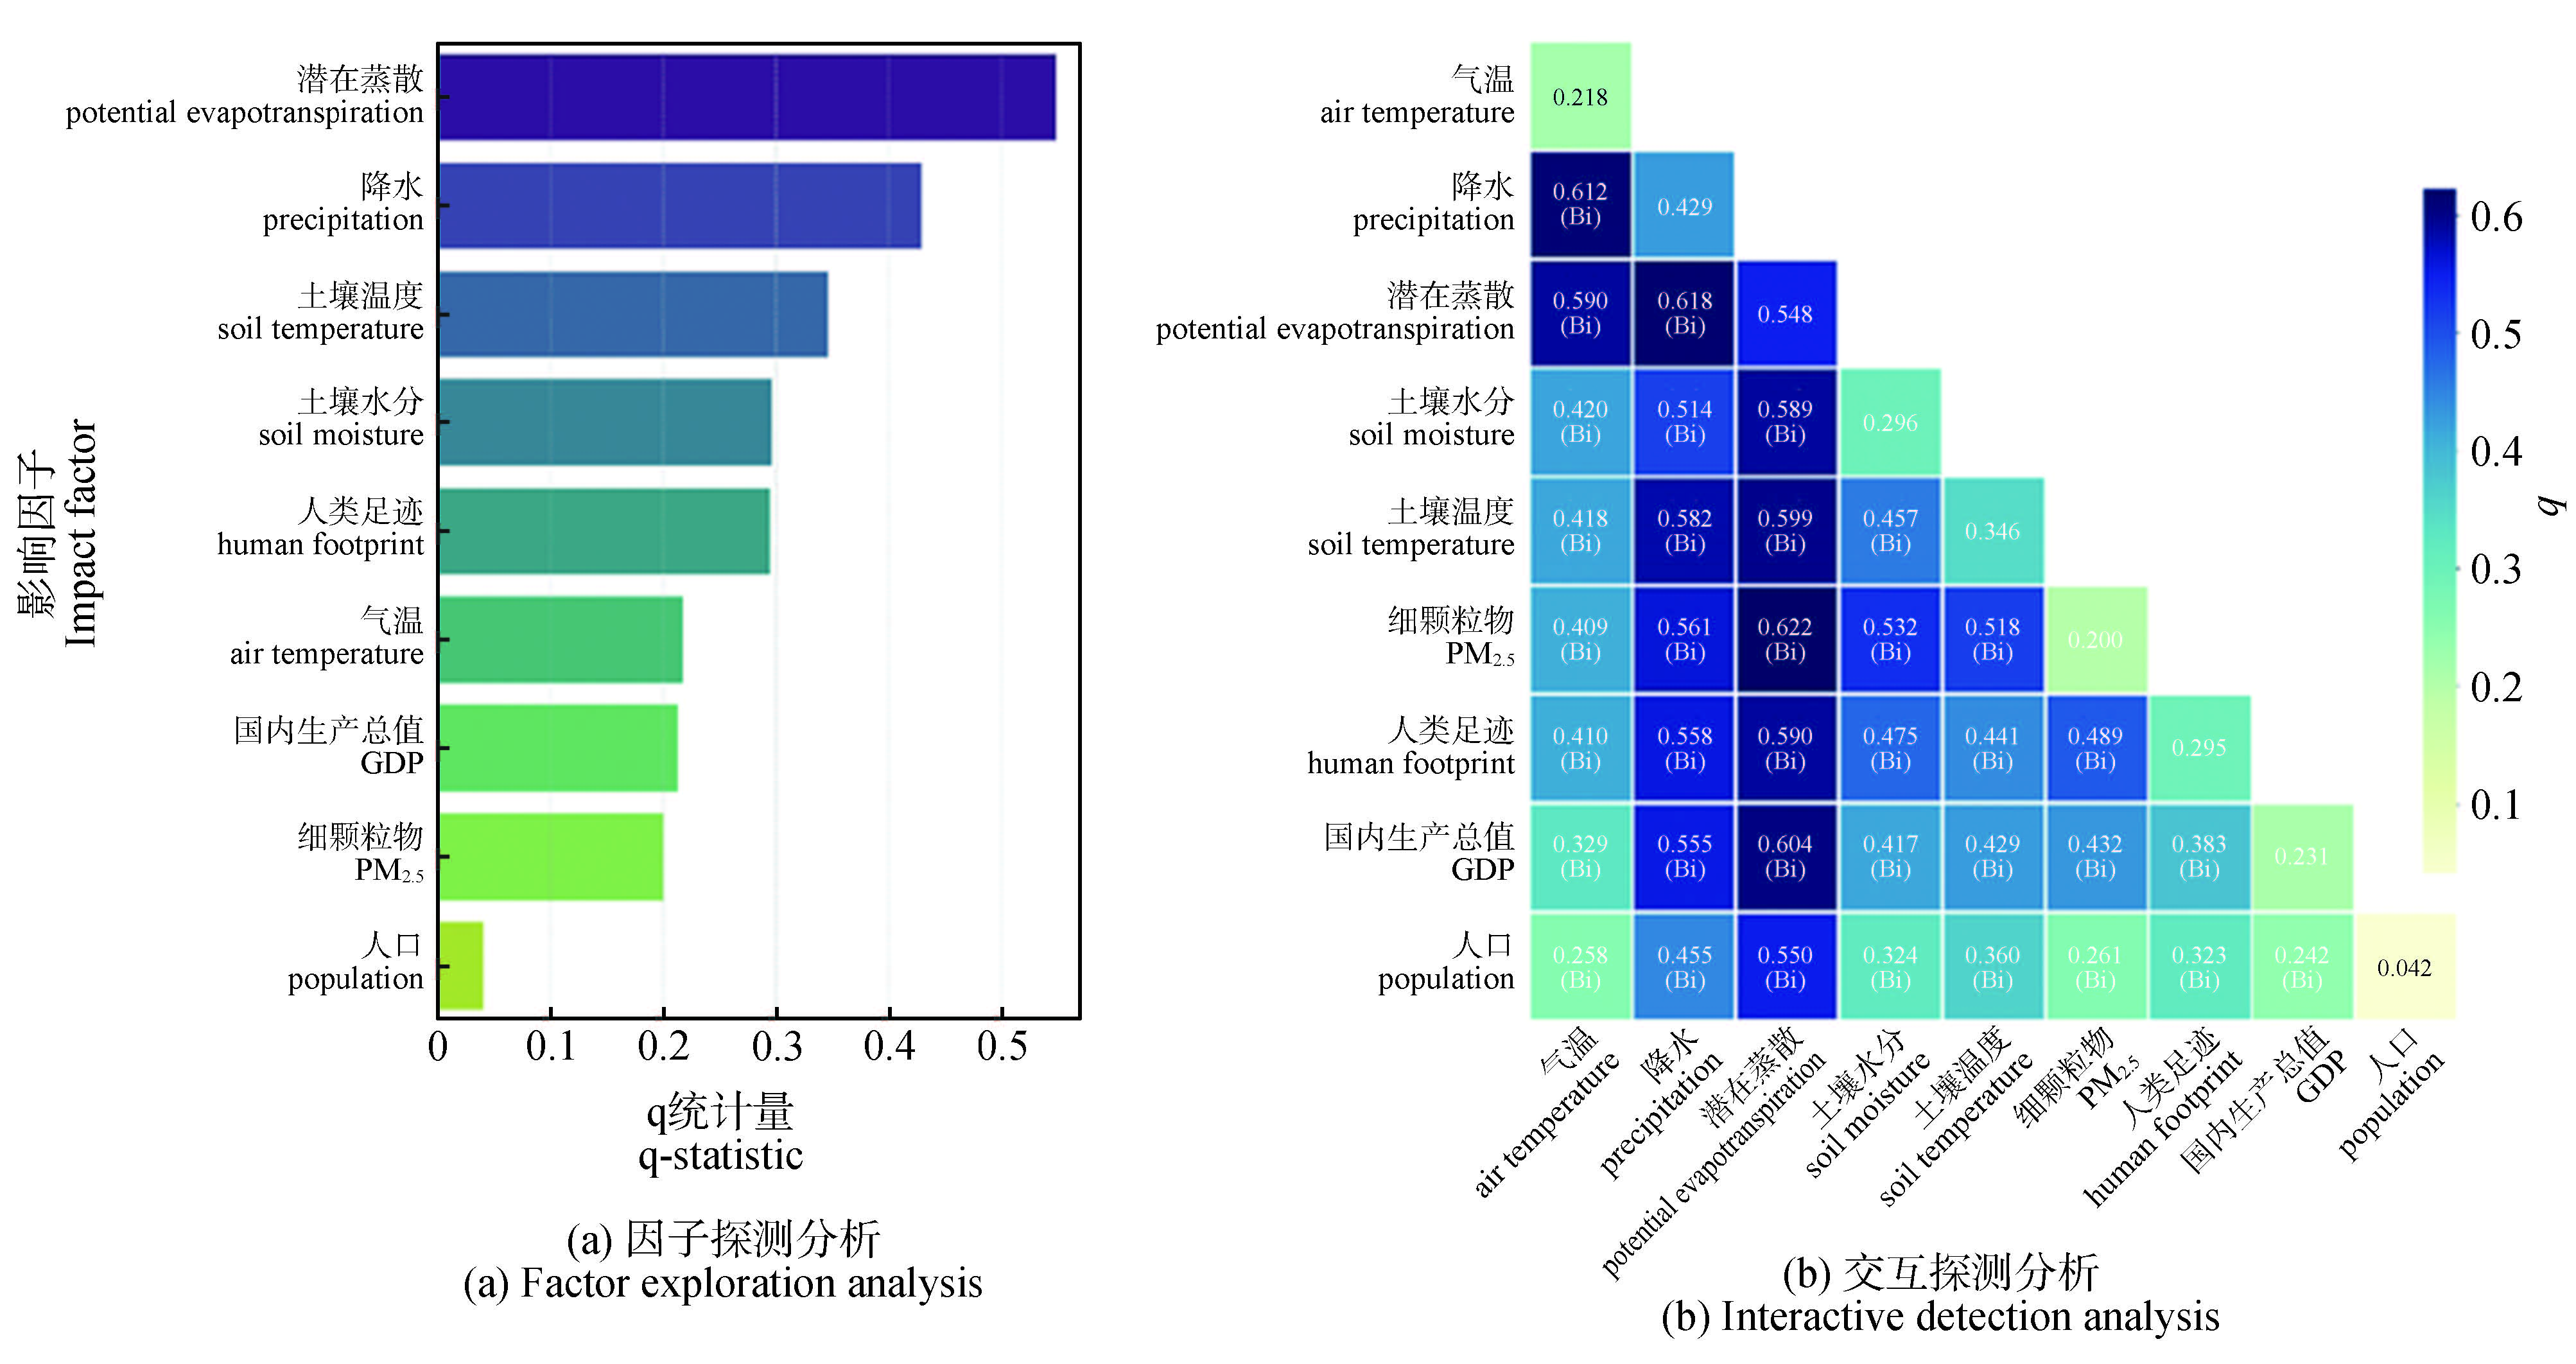
To investigate the spatiotemporal evolution characteristics and driving mechanisms of forest ecosystem quality during the transformation of resource-exhausted cities, this study selected Hegang City as the research area. Based on long-term seamless Landsat time-series datasets and MODIS products, the ecological quality index (EQI) was constructed. The Sen's slope estimator, Mann-Kendall test, and Hurst exponent were employed to analyze the spatiotemporal changes and future trends of forest EQI in Hegang from 2000 to 2025. Finally, the geographical detector model was used to quantitatively analyze the driving forces of natural and anthropogenic factors on the spatial differentiation of EQI. The results showed that, spatially, the EQI exhibited a significant distribution pattern of “high in the northwest and low in the southeast.” The forest areas in the Lesser Khingan Mountains in the northwest showed excellent ecological quality, whereas the southeastern plains and urban built-up areas, subject to intense human disturbance, had relatively lower quality. Temporally, 64.9% of the total area showed an improving trend in EQI, mainly concentrated in the northwestern forest-covered zones and central ecological restoration areas. Furthermore, 52.71% of the area is projected to continue improving in the future, while 34.49% of the degraded areas are primarily located along the urban expansion fringes. The driving mechanism analysis revealed that potential evapotranspiration(PET, q=0.548) was the dominant natural factors explaining the spatial heterogeneity of EQI, followed by precipitation(q=0.429), while the human footprint product(HFP, q=0.295) was the most significant anthropogenic driver. The interactions between all factors demonstrated bi-factor enhancement and non-linear enhancement effects, with the interaction between PET and PM2.5 showing the strongest explanatory power(q=0.622). These findings can provide a scientific basis and decision-making support for the ecological restoration and sustainable development of resource-exhausted cities in the old industrial base of Northeast China.
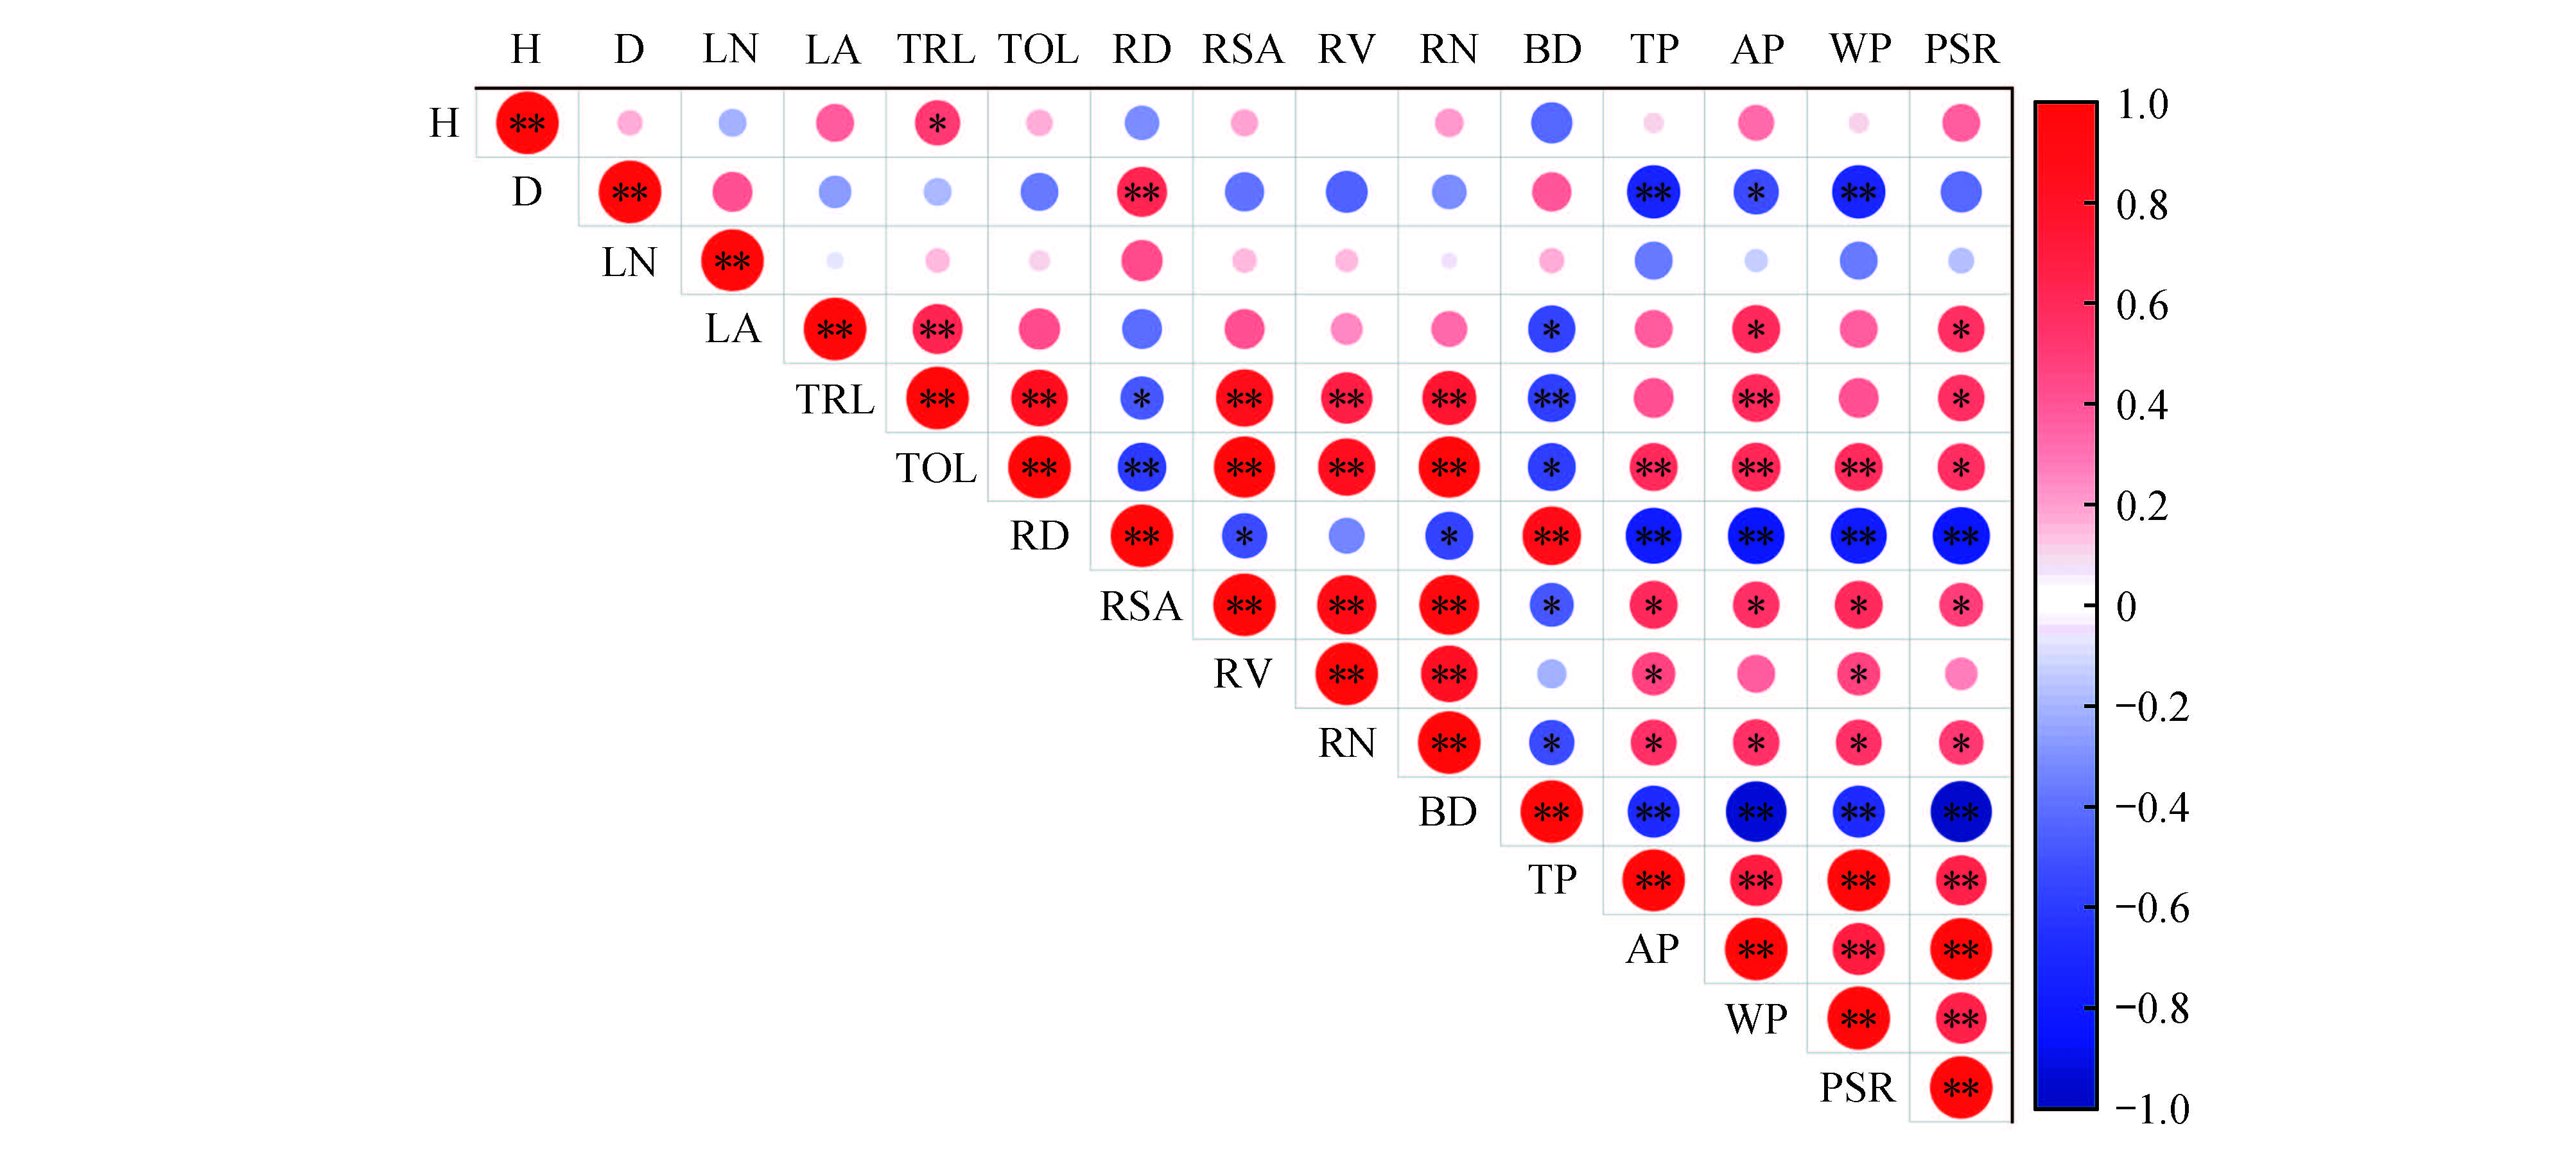
To explore the regulatory mechanisms of the emergence and growth of Schisandra chinensis with the treatment of different proportion composite substrates, the optimal technical solutions for its industrialized seedling cultivation are screened. Using peat carbon, perlite and bark powder as materials, 5 composite substrates with different portion perlite and bark powder (T1-T5) were set. T1 (100% bark powder), T2 (10% perlite +90% bark powder), T3 (20% perlite +80% bark powder), T4 (40% perlite +60% bark powder), T5 (50% perlite +50% bark powder). After 50 days of seeds planting with peat carbon (CK) as a control, the physical properties of each substrate (including porosity, bulk density) were systematically measured. Seed emergence of Schisandra chinensis was monitored, and key seedling growth metrics, including height, basal diameter, and root morphology were assessed. Correlation analysis was used to reveal the relationship between substrate physicochemical properties and seedling quality. The analysis of comprehensive evaluation factors was employed to screen the optimal substrate. Significant differences were observed in the physical properties between the different composite substrates: the aeration porosity and pore size ratio of the composite substrates were significantly higher than those of the control (P<0.05), while the bulk density and water-holding porosity were significantly lower than those of the control (P<0.05). The highest aeration porosity (19.13%) and pore size ratio (0.48) among all treatments were achieved under T5. During the germination stage, the highest emergence rate was observed under T3, reaching a value of 55.6%. During the seedling growth stage, the major growth indicators, such as plant height, basal diameter, root length, and root diameter were showed significant superiority under T4 (40% perlite+60% bark powder) compared to control groups (P<0.05). Correlation analysis confirmed a significant positive correlation between both aeration porosity and the emergence rate (P<0.05), and the water-holding porosity and the root development (P<0.05). The overall growth potential of Schisandra chinensis seedlings was maximized under the T4 (40% perlite+60% bark powder), which also ensured a high emergence rate, showing significant advantages in saving seeds and improving plant quality. This provides a viable technical pathway for the industrialized cultivation of Schisandra chinensis.
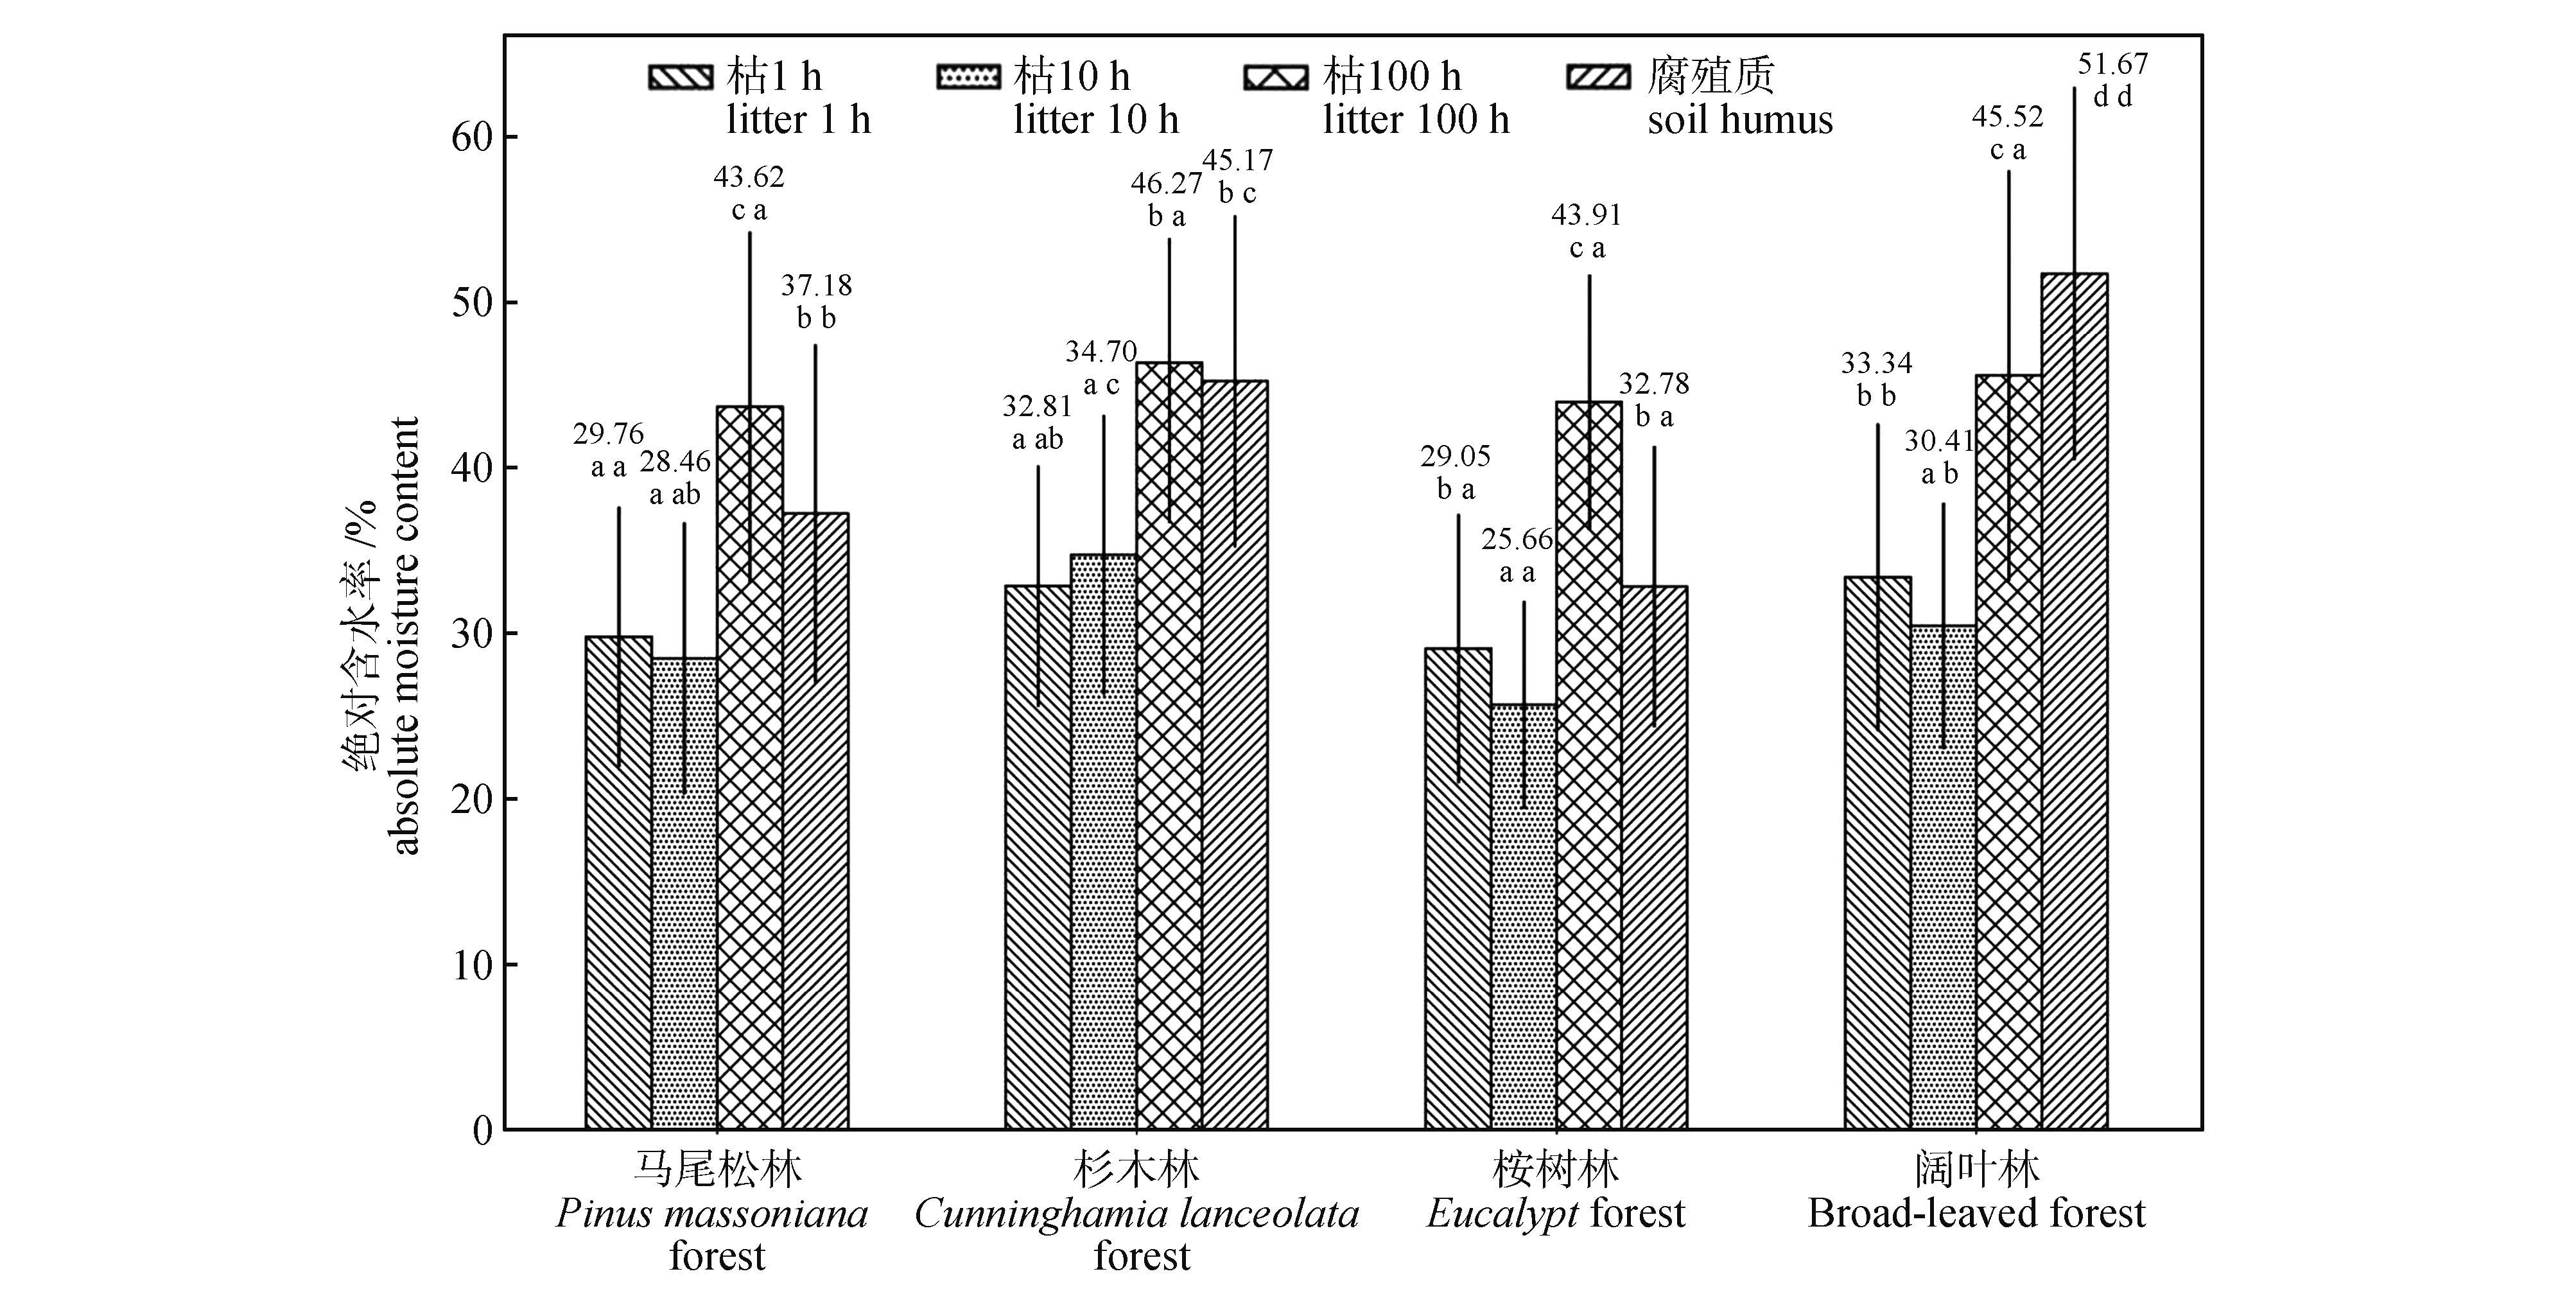
To clarify the differences in the surface dead fuel moisture content among different forest types in Guangxi and to identify the key environmental factors affecting these variations, four typical forest types in Guangxi (Pinus massoniana forest, Cunninghamia lanceolata forest, Eucalyptus forest and broadleaved forest) were selected as research subjects. During the peak fire prevention period, surface dead fuel samples were collected and their absolute moisture content was measured. Multiple comparison analysis was conducted to examine the differences in moisture content among various forest types and dead fuels. Redundancy analysis (RDA) was used to explore the effects of topographic factors and stand structural factors on dead fuel moisture content. The results indicated that the absolute moisture content of surface dead fuels varied significantly among different forest types, generally in the order of broadleaved forest, Cunninghamia lanceolata fores, Pinus massoniana forest and Eucalyptus forest. Within each forest type, coarse dead fuels and humus showed significantly higher moisture content than fine dead fuels. Elevation was found to be the most influential topographic factor affecting surface dead fuel moisture content, fo llowed by slope aspect. Stand density and canopy density were the most important stand factors influencing the dead fuel moisture content in Cunninghamia lanceolata, Pinus massoniana, and Eucalyptus forests. In broadleaved forests, multiple stand factors influenced the moisture content, but their effects were more dispersed. During the peak fire prevention period, fire risk monitoring should focus on forest types with lower moisture content, and differentiated fuel management measures should be developed based on topographic and stand characteristics.
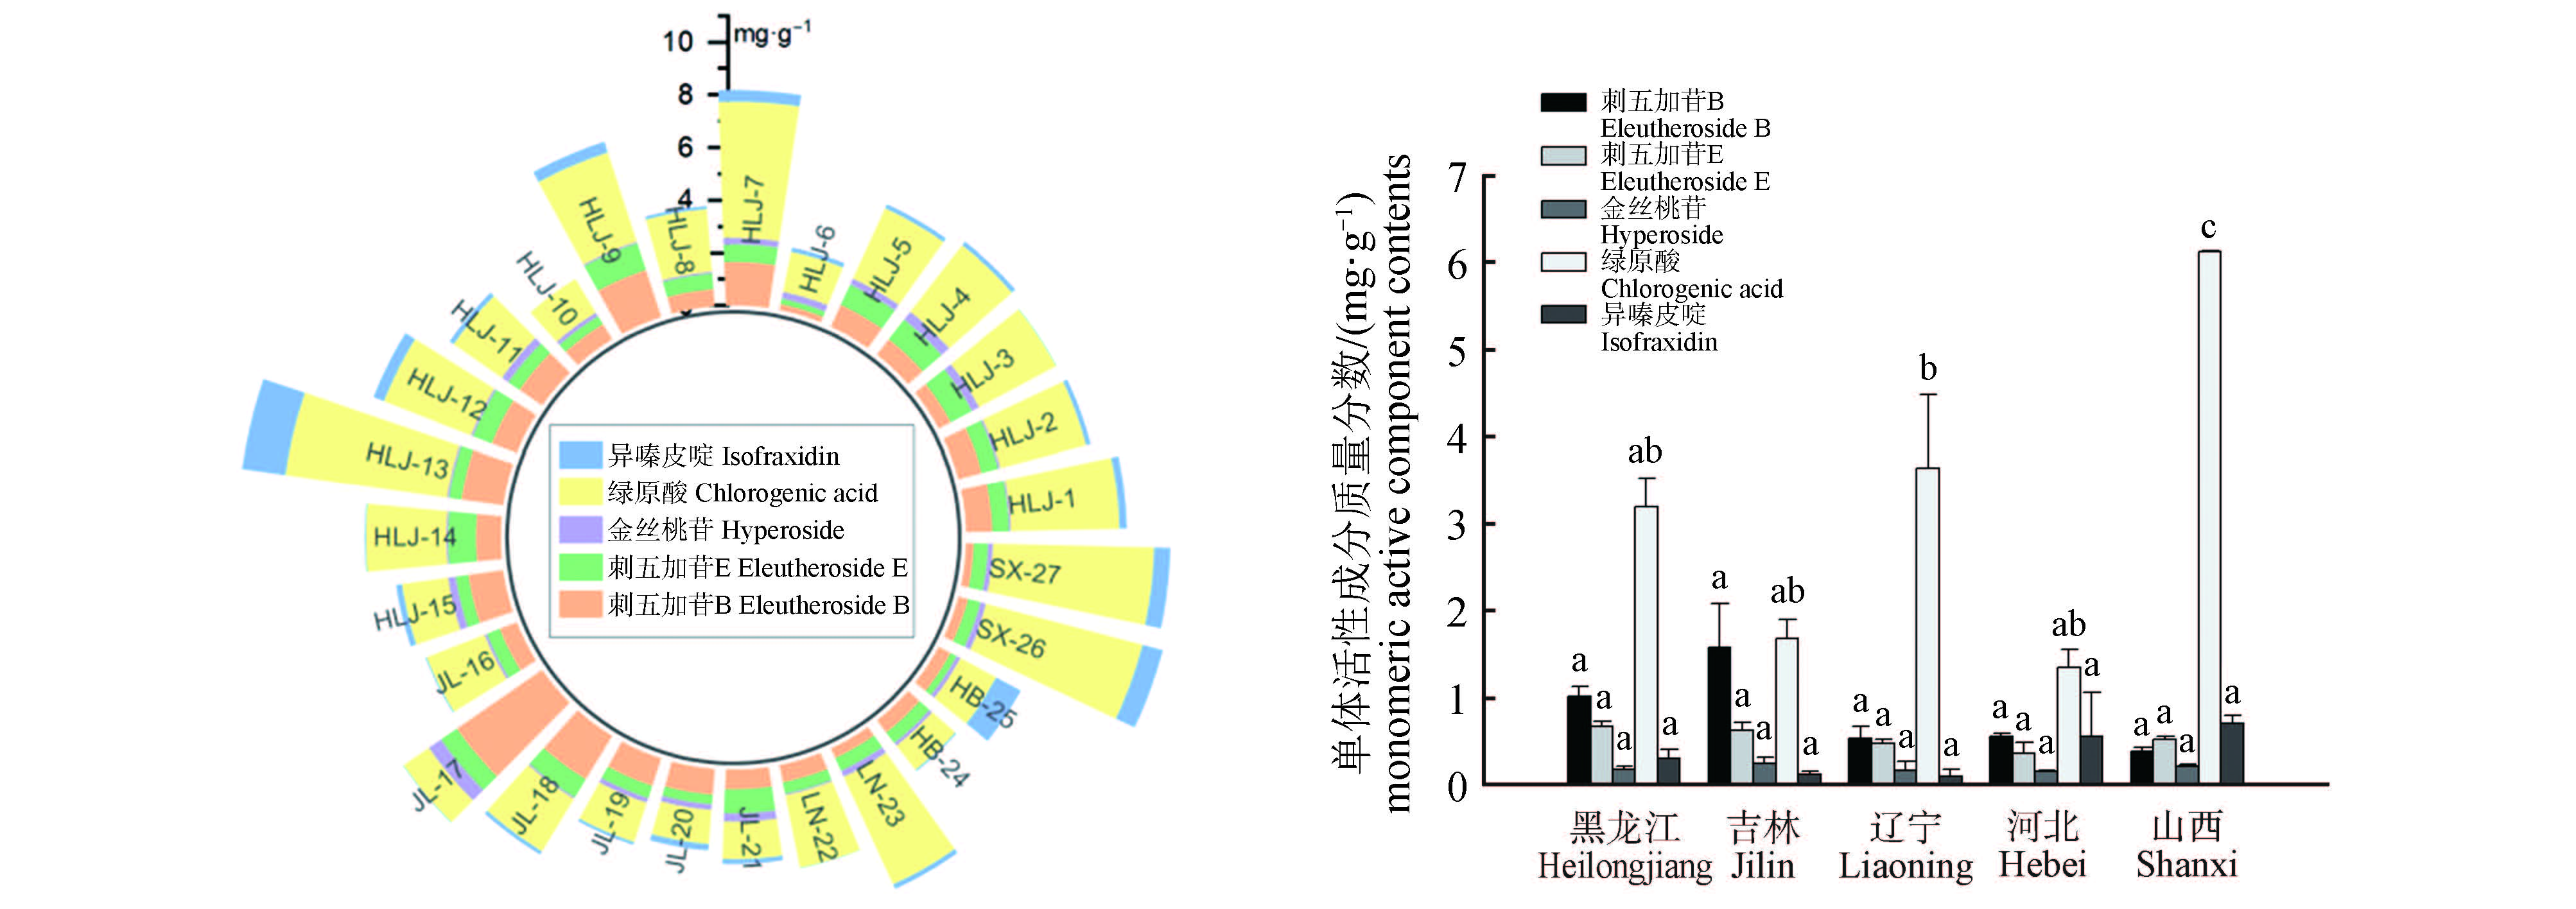
Using 10 indicators including five monomer active ingredients such as eleutheroside B, three types of active substances such as total saccharides and two indicators specified in the pharmacopoeia such as total ash and methanol-soluble extract content, a comprehensive evaluation was conducted on wild Eleutherococcus senticosus resources from Heilongjiang, Jilin, Liaoning, Hebei, and Shanxi provinces, through a combination of single-indicator evaluation and analytic hierarchy process-entropy weight method evaluation. The results showed that there were significant variations in all evaluation indicators among the 27 samples. The maximum difference in the content of isofraxidin between two samples from Heilongjiang was over 700 times, a difference of 16 times in the content of eleutheroside B between two sample from Jilin and Heilongjiang and a difference fo nearly 6 times in the comprehensive evaluation score between the two sample from Heilongjiang and Hebei. From the average level of each province, samples from Hebei were lower than those from other provinces in most indicators, with important indicators such as methanol-soluble extract, eleutheroside B, eleutheroside E, and chlorogenic acid content being more than 40% lower than those from Heilongjiang. Although samples from Shanxi had advantages in methanol-soluble extract, chlorogenic acid, total saccharides content and comprehensive evaluation score, but the total ash and eleutheroside B content did not meet the pharmacopoeia requirements. In the comprehensive evaluation using the analytic hierarchy process-entropy weight method, samples from Heilongjiang and Shanxi exhibited superior scores. Notably, the sample from Heilongjiang scored over 14% higher than the sample from Jilin. The further correlation analysis between evaluation indicators and environmental factors revealed significant positive correlations (P<0.05) between annual average temperature, annual average precipitation, and annual sunshine hours with total ash, total saponin, and isofraxidin content, respectively. Therefore, considering individual indicators, pharmacopoeial standards, and comprehensive evaluation scores, Heilongjiang is a high-quality production and provenance area for Eleutherococcus senticosus, which is related to its growth conditions of lower temperature and higher precipitation.
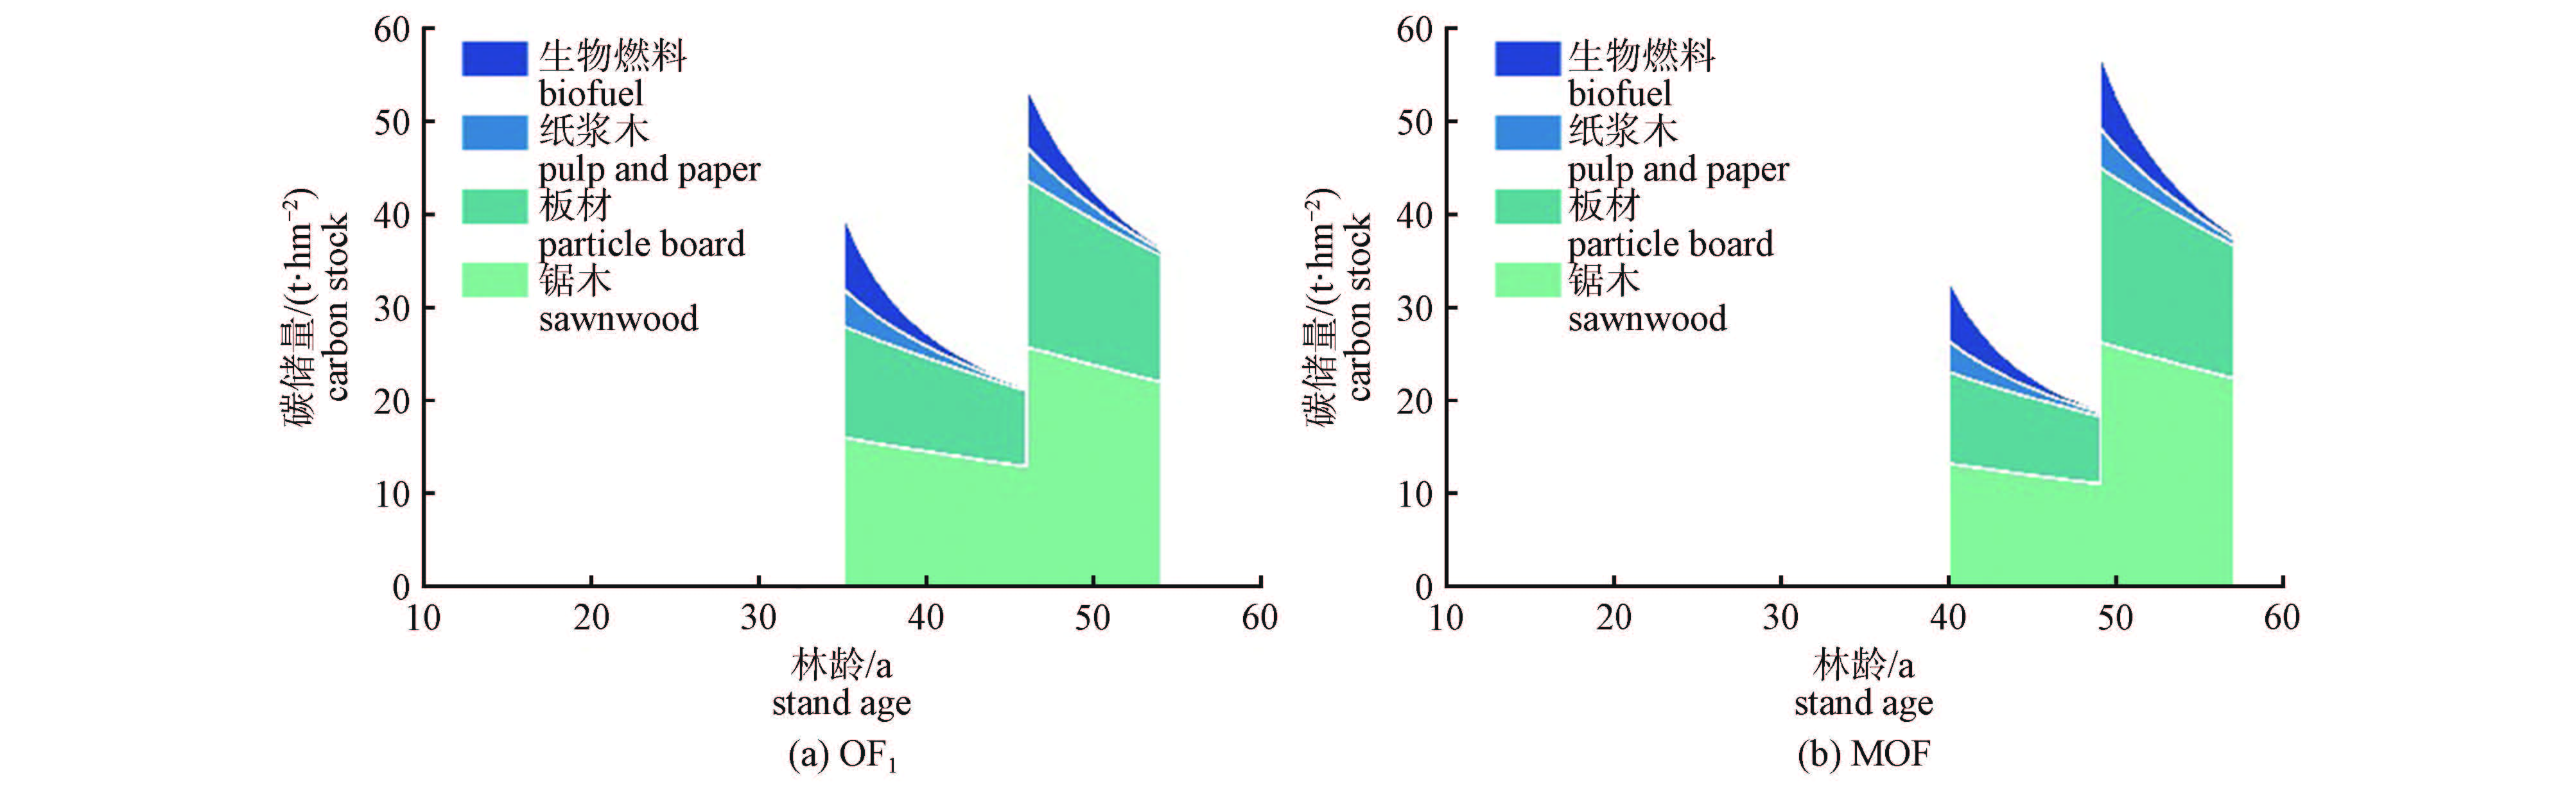
To quantify the trade-off between carbon stock and wood production in Mongolian pine plantations and to integrate simulation and optimization approaches to explore optimal management strategies that simultaneously increase carbon stock and wood production, thereby enhancing the sustainable management of Mongolian pine plantations. Based on the Mongolian pine stand growth simulator, this study investigated the dynamics of wood production and carbon stocks in the live tree carbon pool, product carbon pool, and dead organic matter carbon pool under different site indices using existing field plots. A multi-objective function incorporating wood production and carbon stock was developed using a multi-attribute utility function, together with the corresponding single-objective functions. The differential evolution algorithm was applied to derive the optimal cutting schedules under different management objectives. Results indicated that in multi-objective management, as site indices improved (site indices increasing from 14-18 m to 21-26 m), the timing of final cutting and thinning were generally postponed. Meanwhile, the mean annual wood production, average total carbon stock, and net present value increased on average by 46.2%, 48.7%, and 54.7%, respectively. When product and dead organic matter carbon pools were incorporated into the carbon accounting framework, the average total carbon stock was 36.2%-44.2% higher than that estimated by considering only the live tree carbon pool. Compared with the single-objective management regime considering only wood production, the rotation length under multi-objective management was extended by 7-10 years, while the mean annual wood production decreased by 1.6%-2.1% and the average total carbon stock increased by 15.9%-29.5%. The study showed that the multi-carbon-pool based carbon stock accounting approach provides a more comprehensive representation of the actual carbon sequestration potential of plantation forests. Based on the trade-off analysis between carbon stock and wood production, a compromise management strategy balancing carbon sequestration and wood production is identified, as it ensures stable wood production while effectively enhancing the carbon sequestration capacity of stands, thus providing a scientific basis for multi-objective management of Mongolian pine plantations.
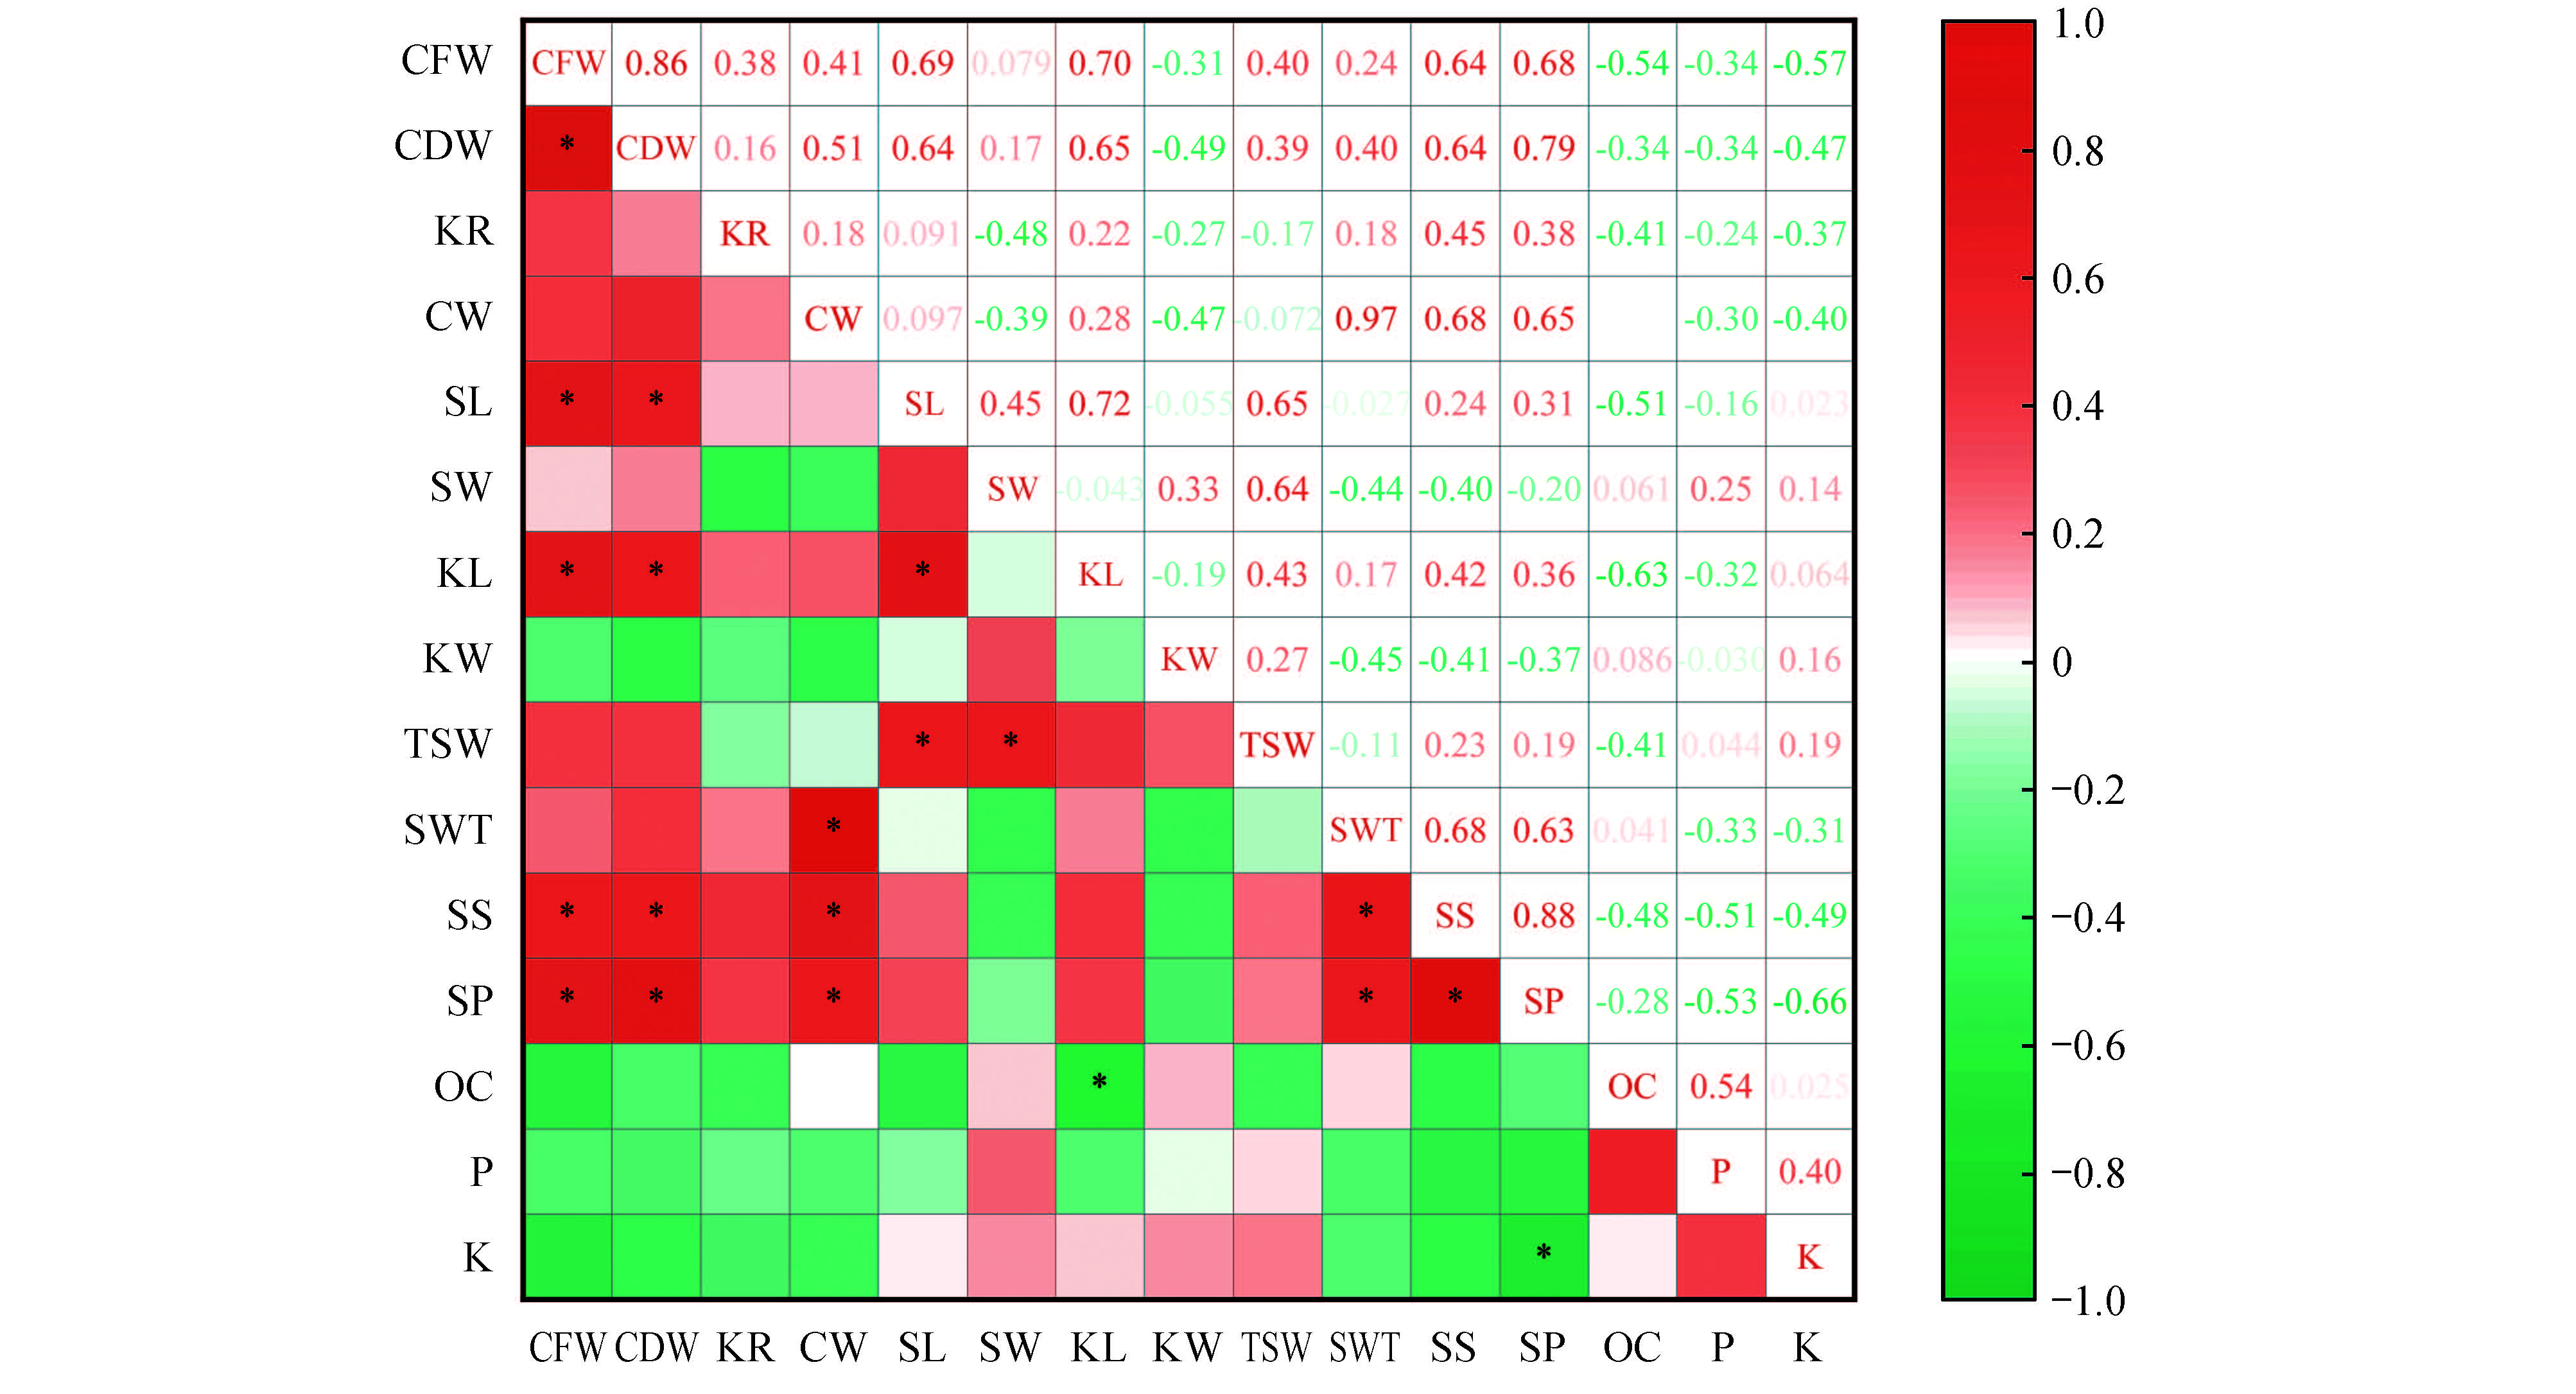
This study aimed to investigate the effects of different combined fertilization treatments on the morphology and nutrient composition of Pinus koraiensis cones and seeds, to identify the optimal fertilization regime for Pinus koraiensis nut forests, and to provide a theoretical basis and practical guidance for scientific fertilization. A 52-year-old Pinus koraiensis plantation was used as the research subject. Three levels of foliar fertilization (amino acid water-soluble fertilizer: 0%, 0.1%, and 0.2%) were designated as no spraying (F1), low-concentration (F2), and high-concentration (F3) foliar fertilization, and four levels of soil fertilization (urea: 0, 50, 100, and 150 kg N·hm-2) were designated as no fertilization (S1), low rate (S2), medium rate (S3), and high rate (S4) soil fertilization, resulting in a total of 12 treatment combinations. The effects of these different fertilization combinations on cone yield, seed morphology and yield, and kernel contents of soluble sugars, soluble protein, oil, phosphorus, and potassium were investigated. A comprehensive evaluation of fertilization efficiency was conducted using correlation analysis, principal component analysis, and economic benefit analysis. The results showed that foliar fertilization significantly increased cone dry weight, per-tree cone and seed yield, and kernel soluble protein content. As foliar fertilizer concentration increased, these parameters increased significantly, with the F3S2 treatment showing the best performance, achieving increases of 31.5% in cone dry weight, 3.45 kg in per-tree cone yield, 0.92 kg in per-tree seed yield, and 47.75% in kernel soluble protein content compared with the control. Soil fertilization alone did not significantly promote kernel oil synthesis. However, low-concentration foliar fertilization (F2) applied alone (F2S1) or combined with low-rate soil fertilization (F2S2) significantly increased oil content by 9.1% to 9.6%. Principal component analysis showed that the F3S2 treatment achieved the highest comprehensive score for cone and seed quality. Analysis of net seed income revealed that the F3S2 treatment had the highest net income (35,693.62 CNY·hm-2), followed by the F3S1 treatment (30,175.67 CNY·hm-2). In conclusion, combined foliar and soil fertilization further enhanced cone yield and promoted nutrient accumulation. To maximize both economic returns and seed quality, the combination of high-concentration (0.2%) foliar fertilization and low-rate (50 kg N·hm-2) soil fertilization is recommended. If application convenience and cost are primary concerns, high-concentration (0.2%) foliar fertilization alone can be used as an alternative.
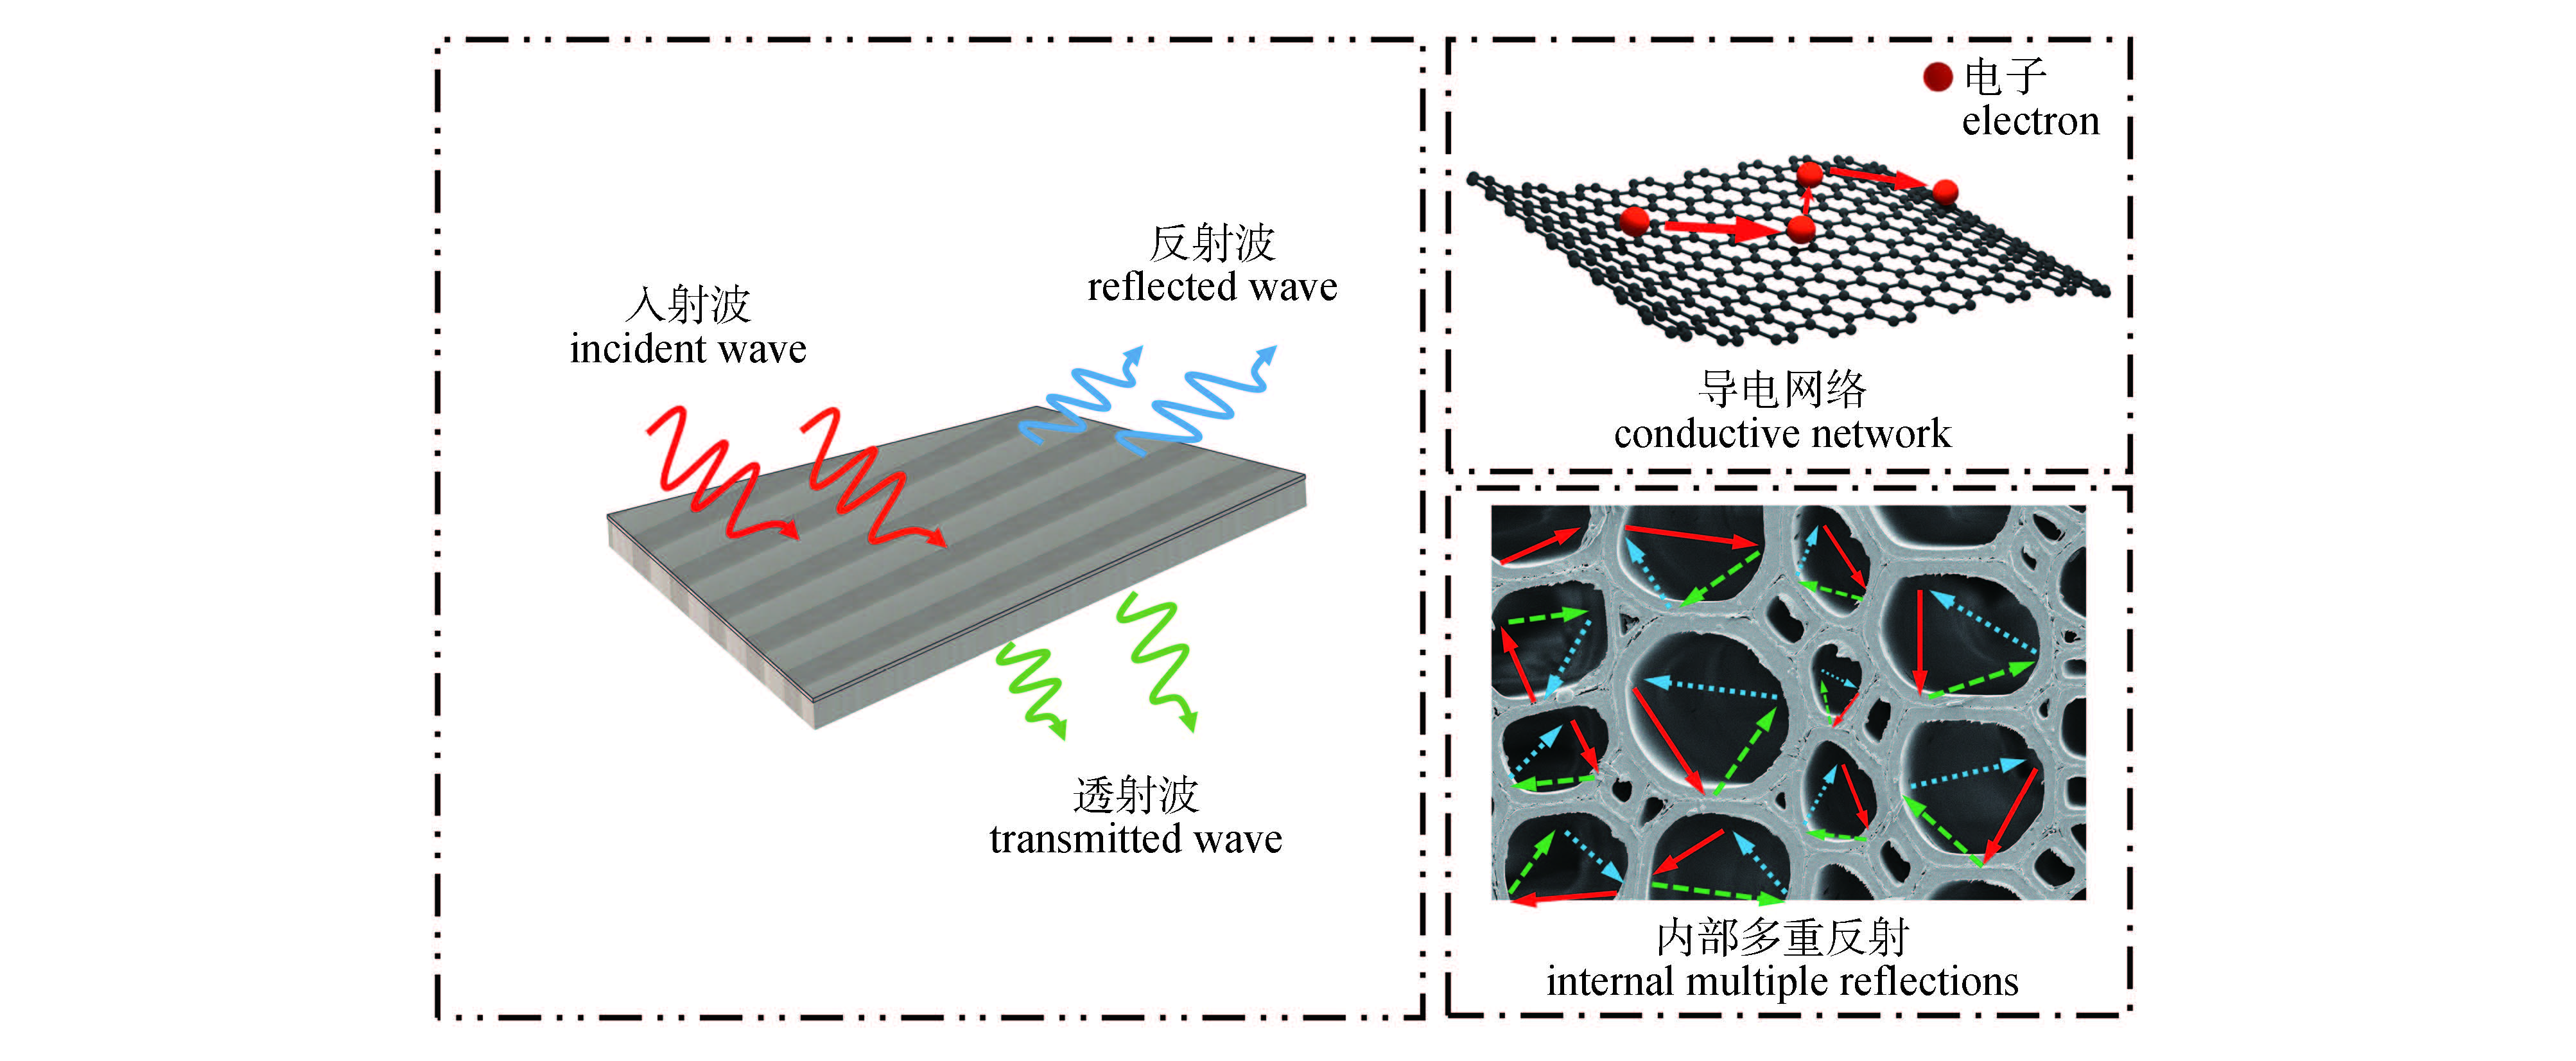
To address the increasingly severe problem of electromagnetic pollution, three common broadleaf woods with significantly different densities-paulownia, basswood, and eucalyptus-were selected. Wood-based carbon materials were prepared using a high-temperature carbonization process, and the relationship between the physicochemical properties and electromagnetic shielding performance of these three materials was systematically compared. The results indicated that after carbonization, the wood retained its natural skeletal structure and porous characteristics; the carbonization process conferred electrical conductivity to the originally insulating wood, with the resulting wood-based carbon materials exhibiting a conductivity of 3.08-3.53 S·cm-1. The total shielding efficiency of all three wood-based carbon materials exceeded 20 dB, meeting the basic requirements for commercial applications. Due to differences in microstructure and density, the three wood types exhibited distinct advantages in electromagnetic shielding performance. Among them, the paulownia-based carbon, with the lowest density, was dominated by absorption loss and was suitable for green shielding applications; the basswood-based carbon, with medium density, struck a balance between absorption and reflection, demonstrating relatively balanced shielding performance; while the eucalyptus-based carbon, with the highest density, exhibited the highest shielding efficiency but had relatively strong reflection loss. This study reveals the mechanism by which density differences influence the continuity and pore structure of the conductive network after carbonization, thereby achieving the synergistic interaction between conductive loss and multiple reflection loss. It provides experimental evidence and theoretical references for the development of high-performance wood-based carbon electromagnetic shielding composites.
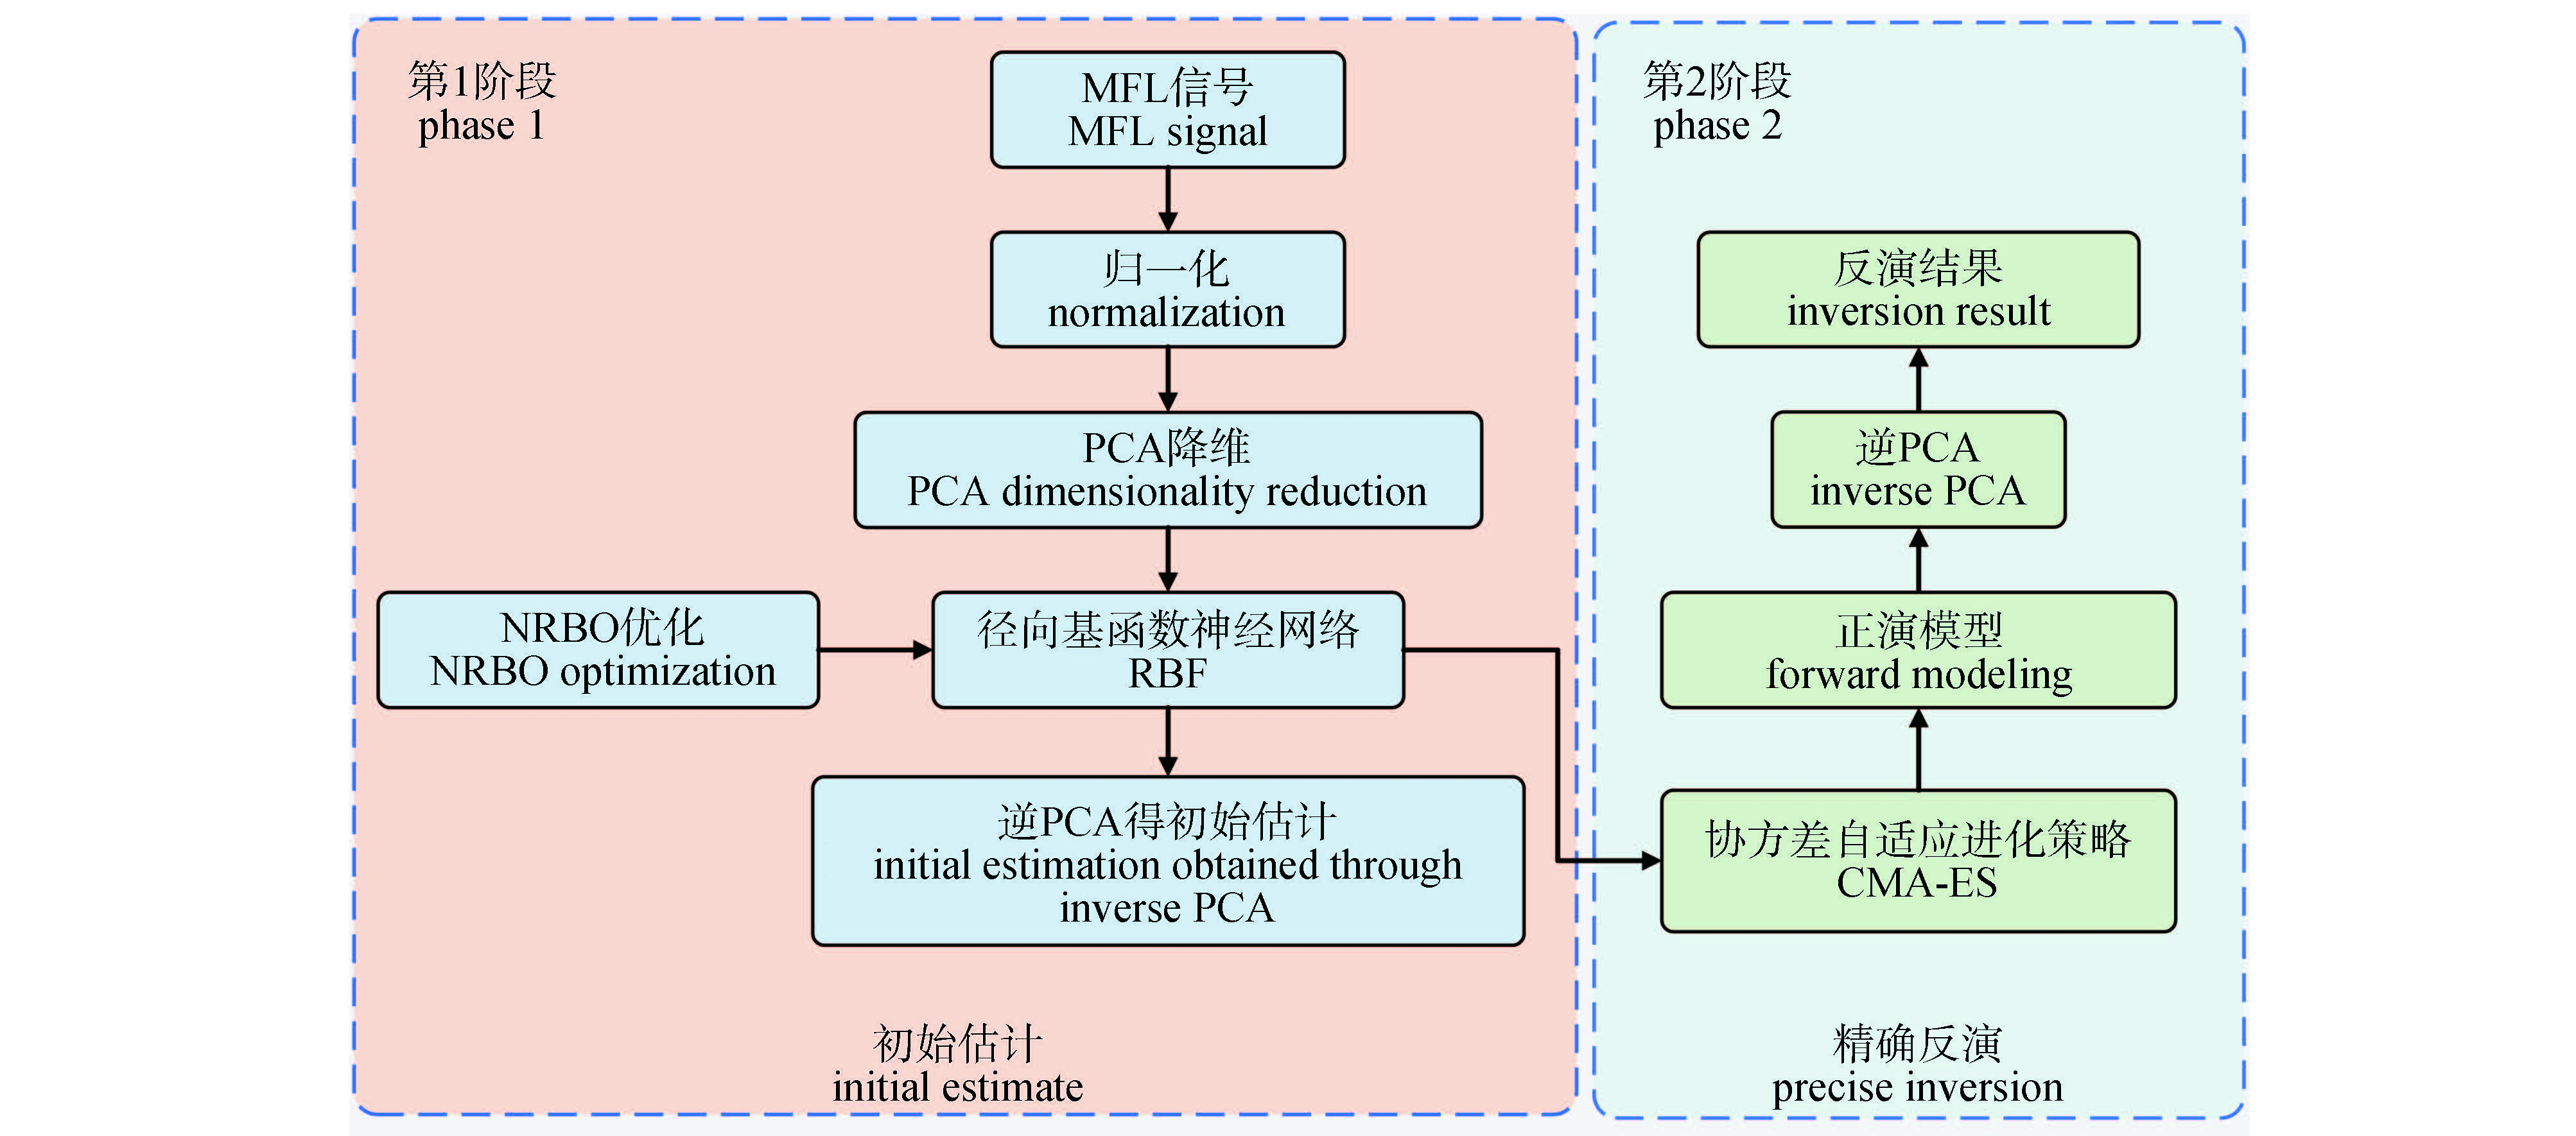
To improve the accuracy of three-dimensional quantitative evaluation for corrosion thinning, pitting, and boundary-discontinuity defects in steel components of forestry equipment under service conditions involving high humidity, mud-water erosion, and cyclic temperature variations, an improved discretized magnetic dipole forward model and a two-stage inversion-based quantification framework are proposed. In the forward modeling stage, a second-order response-driven adaptive mesh refinement strategy and a three-point surface-element quadrature scheme are introduced to enhance the characterization of pit edges and discontinuity zones while controlling the number of nodes. In the inversion stage, principal component analysis (PCA) is first employed to reduce the dimensionality of the defect description and constrain the search space, while the Newton–Raphson optimizer is used to optimize the hyperparameters of the radial basis function (RBF) model to obtain robust initial estimates. In the second stage, the covariance matrix adaptation evolution strategy is adopted to further refine the solution in the low-dimensional space by coupling it with the forward model. Simulation results demonstrate that the proposed forward model achieves accuracy close to that of the finite element model while significantly reducing computational time, and that the inversion framework provides more stable reconstructions for defects with diverse morphologies. The proposed method can be embedded into intelligent forestry condition monitoring and predictive maintenance systems, thereby providing a quantitative basis for risk assessment, maintenance prioritization, and safety management of forestry equipment.
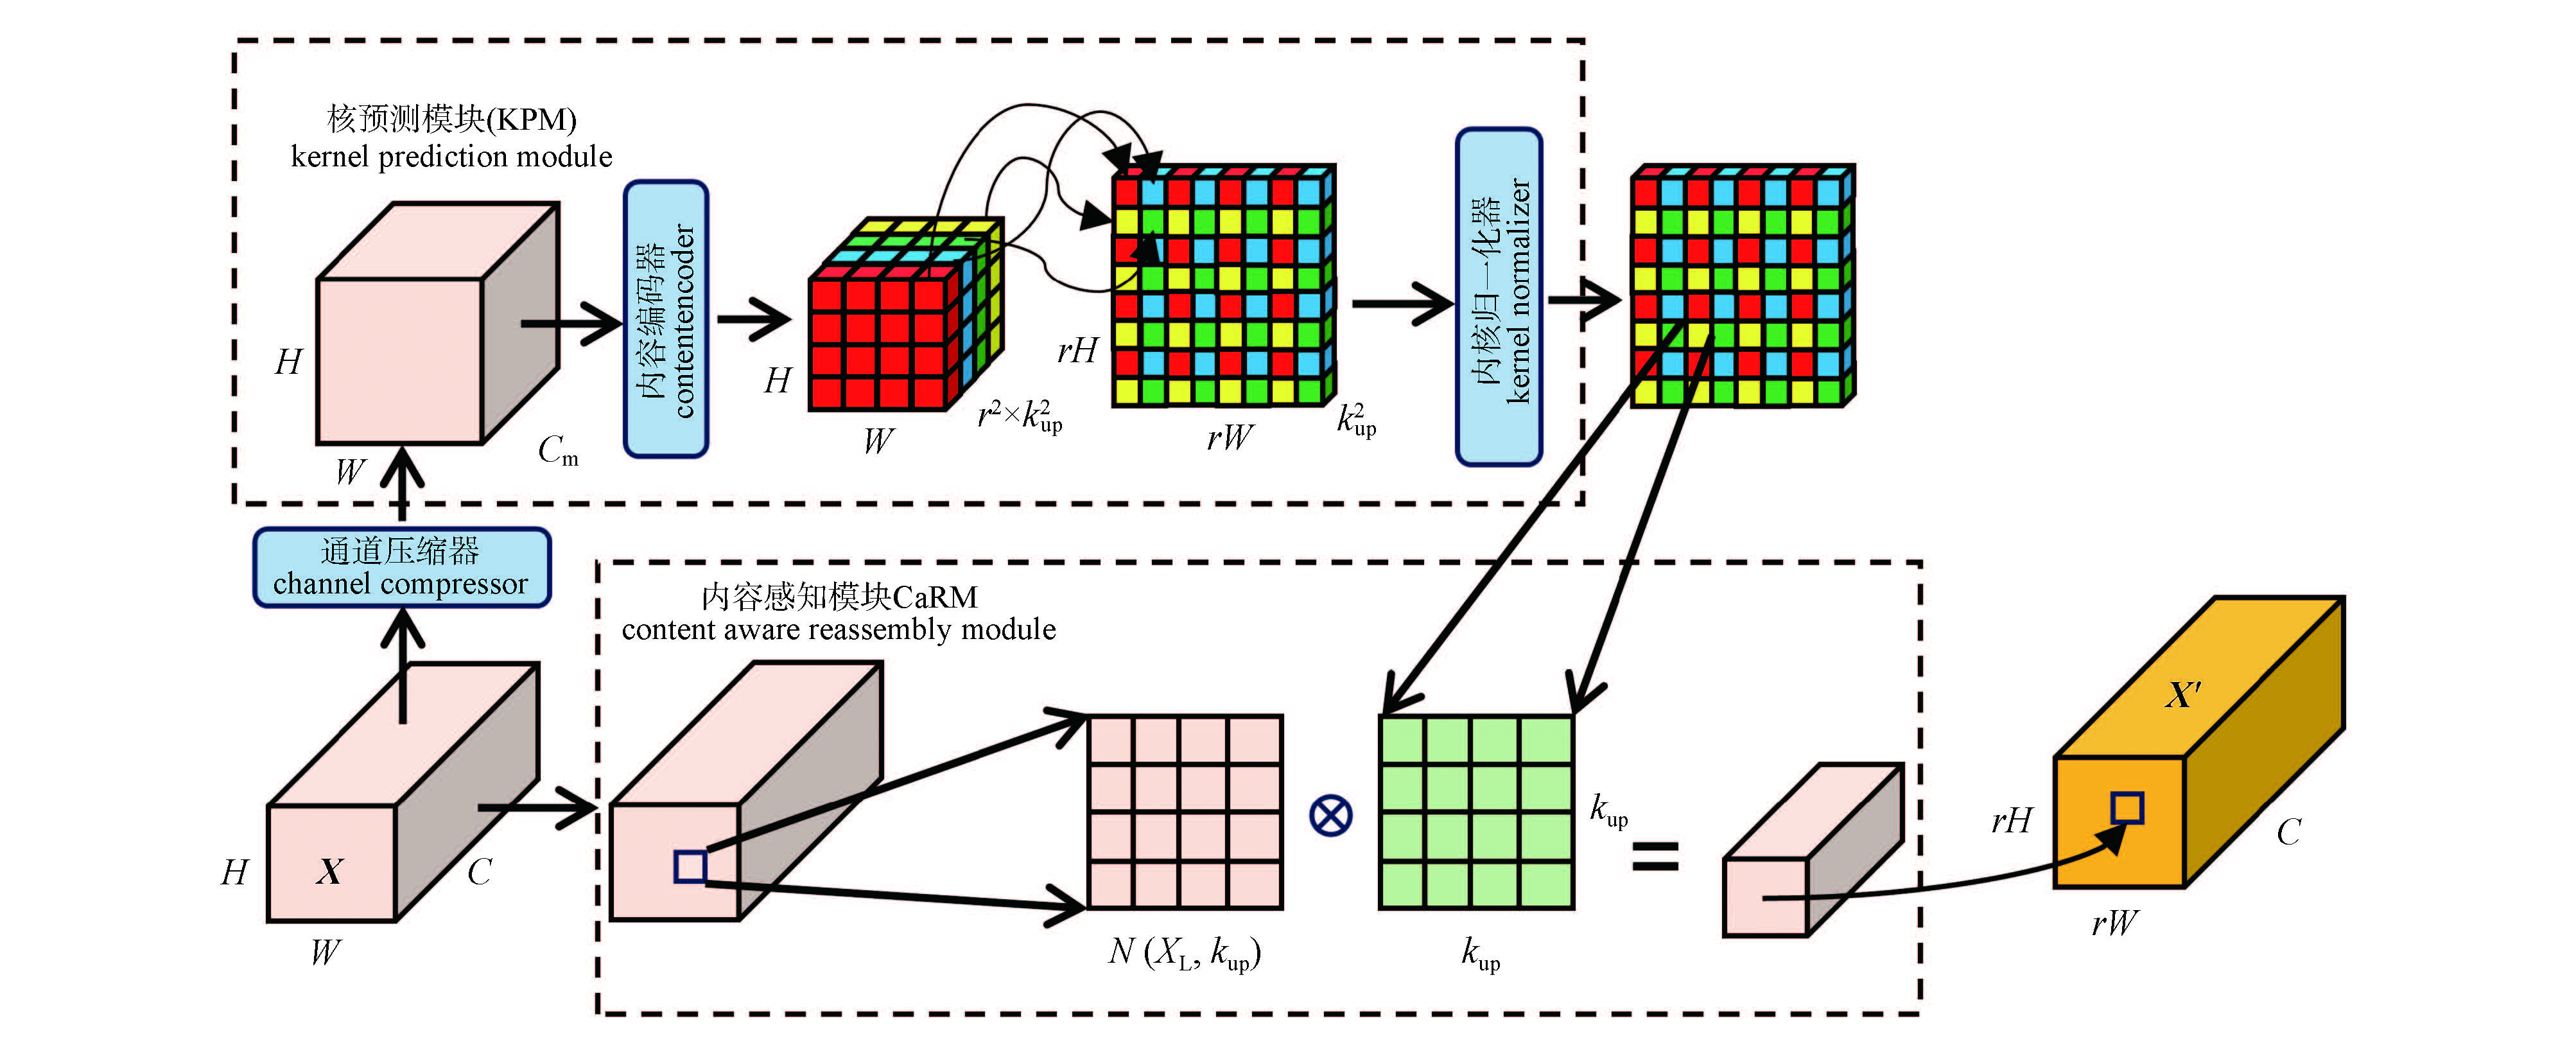
Accurate identification of wooden chair legs and localization of grasping positions are crucial for achieving efficient robotic loading operations. However, existing instance segmentation-based image processing algorithms often struggle to balance accuracy and speed, and their large number of parameters hinders practical deployment in industrial scenarios. Furthermore, these algorithms are prone to missed detections and false detections in complex environments. To address the aforementioned issues, this paper proposes an improved YOLOv11n-seg model. By incorporating lightweight modules and a novel loss function, the model achieves a favorable balance between accuracy and efficiency, thereby optimizing its deployment performance. The specific improvements are as follows: firstly, RepViT is introduced as the backbone network to enhance feature extraction capability while reducing computational complexity. Secondly, the lightweight dynamic upsampler DySample is adopted in the neck network to improve feature fusion efficiency. Finally, Shape-IoU is used to replace the traditional CIoU Loss loss function, optimizing the regression accuracy of bounding boxes. Results of ablation experiments and comparative experiments demonstrate that the improved YOLOv11n-seg algorithm outperforms the original model in both inference speed and segmentation accuracy. Specifically, the total number of model parameters is reduced by 11.31%, the floating-point operations (FLOPs) are decreased by 9.62%, and the mean average precision for segmentation (mAP@0.5:0.95) is increased by 4.61 percentage points. These findings validate the effectiveness of the improved algorithm and provide technical support for the subsequent precise positioning and grasping of wooden chair legs by robots.
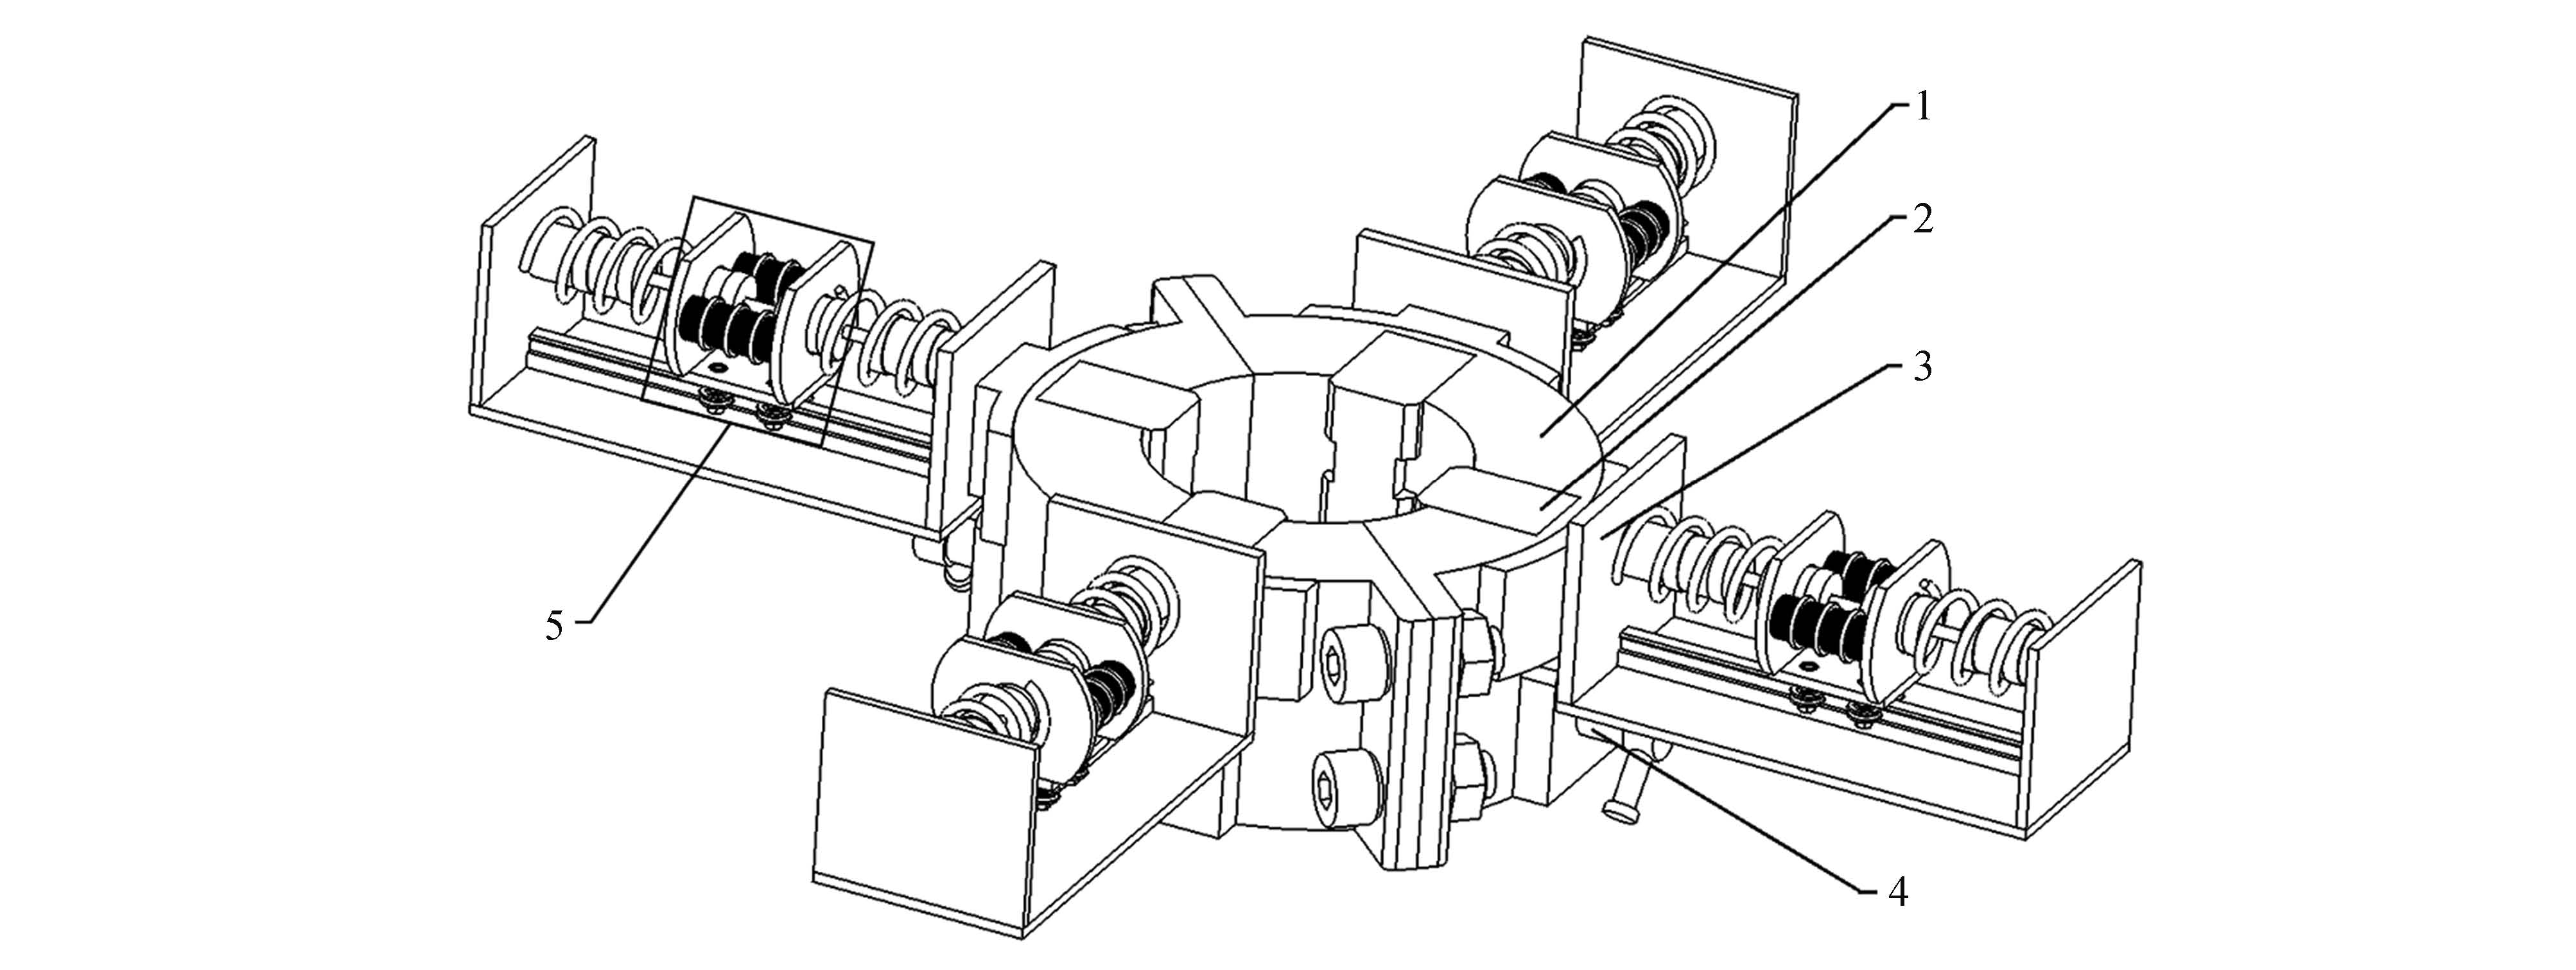
In order to solve the problem of self-power supply in forest monitoring system, this paper proposes a kind of power generation device based on tree swing, which uses the driving energy collector of trees to convert mechanical energy into electric energy through the principle of electromagnetic induction. Firstly, the structure of the energy collector is designed and the working principle of the power generation device is analyzed. Secondly, the differential equation of tree vibration is established, and the mathematical model between the change of the tree's swing angle and the wind moment and the tree's own parameters is derived. Based on the dynamic equation of the electromagnetic vehicle in the energy collector under the forced vibration of the tree, the displacement response of the electromagnetic vehicle is analyzed. Using Ansys Maxwell software to simulate the electromagnetic vehicle and the change law of the induced electromotive force of the single-sided coil. The dynamic model and electromagnetic simulation results show that the displacement response of the electromagnetic vehicle presents a “beating” change law, with a maximum value of 219.38 mm, the maximum induced electromotive force generated by the coil winding is 3.7 V, and the average induced electromotive force is 1.19 V. This study confirms that the power generation device based on tree swing can generate electricity effectively, which provides ideas and solutions for the self-power supply system of forest monitoring.
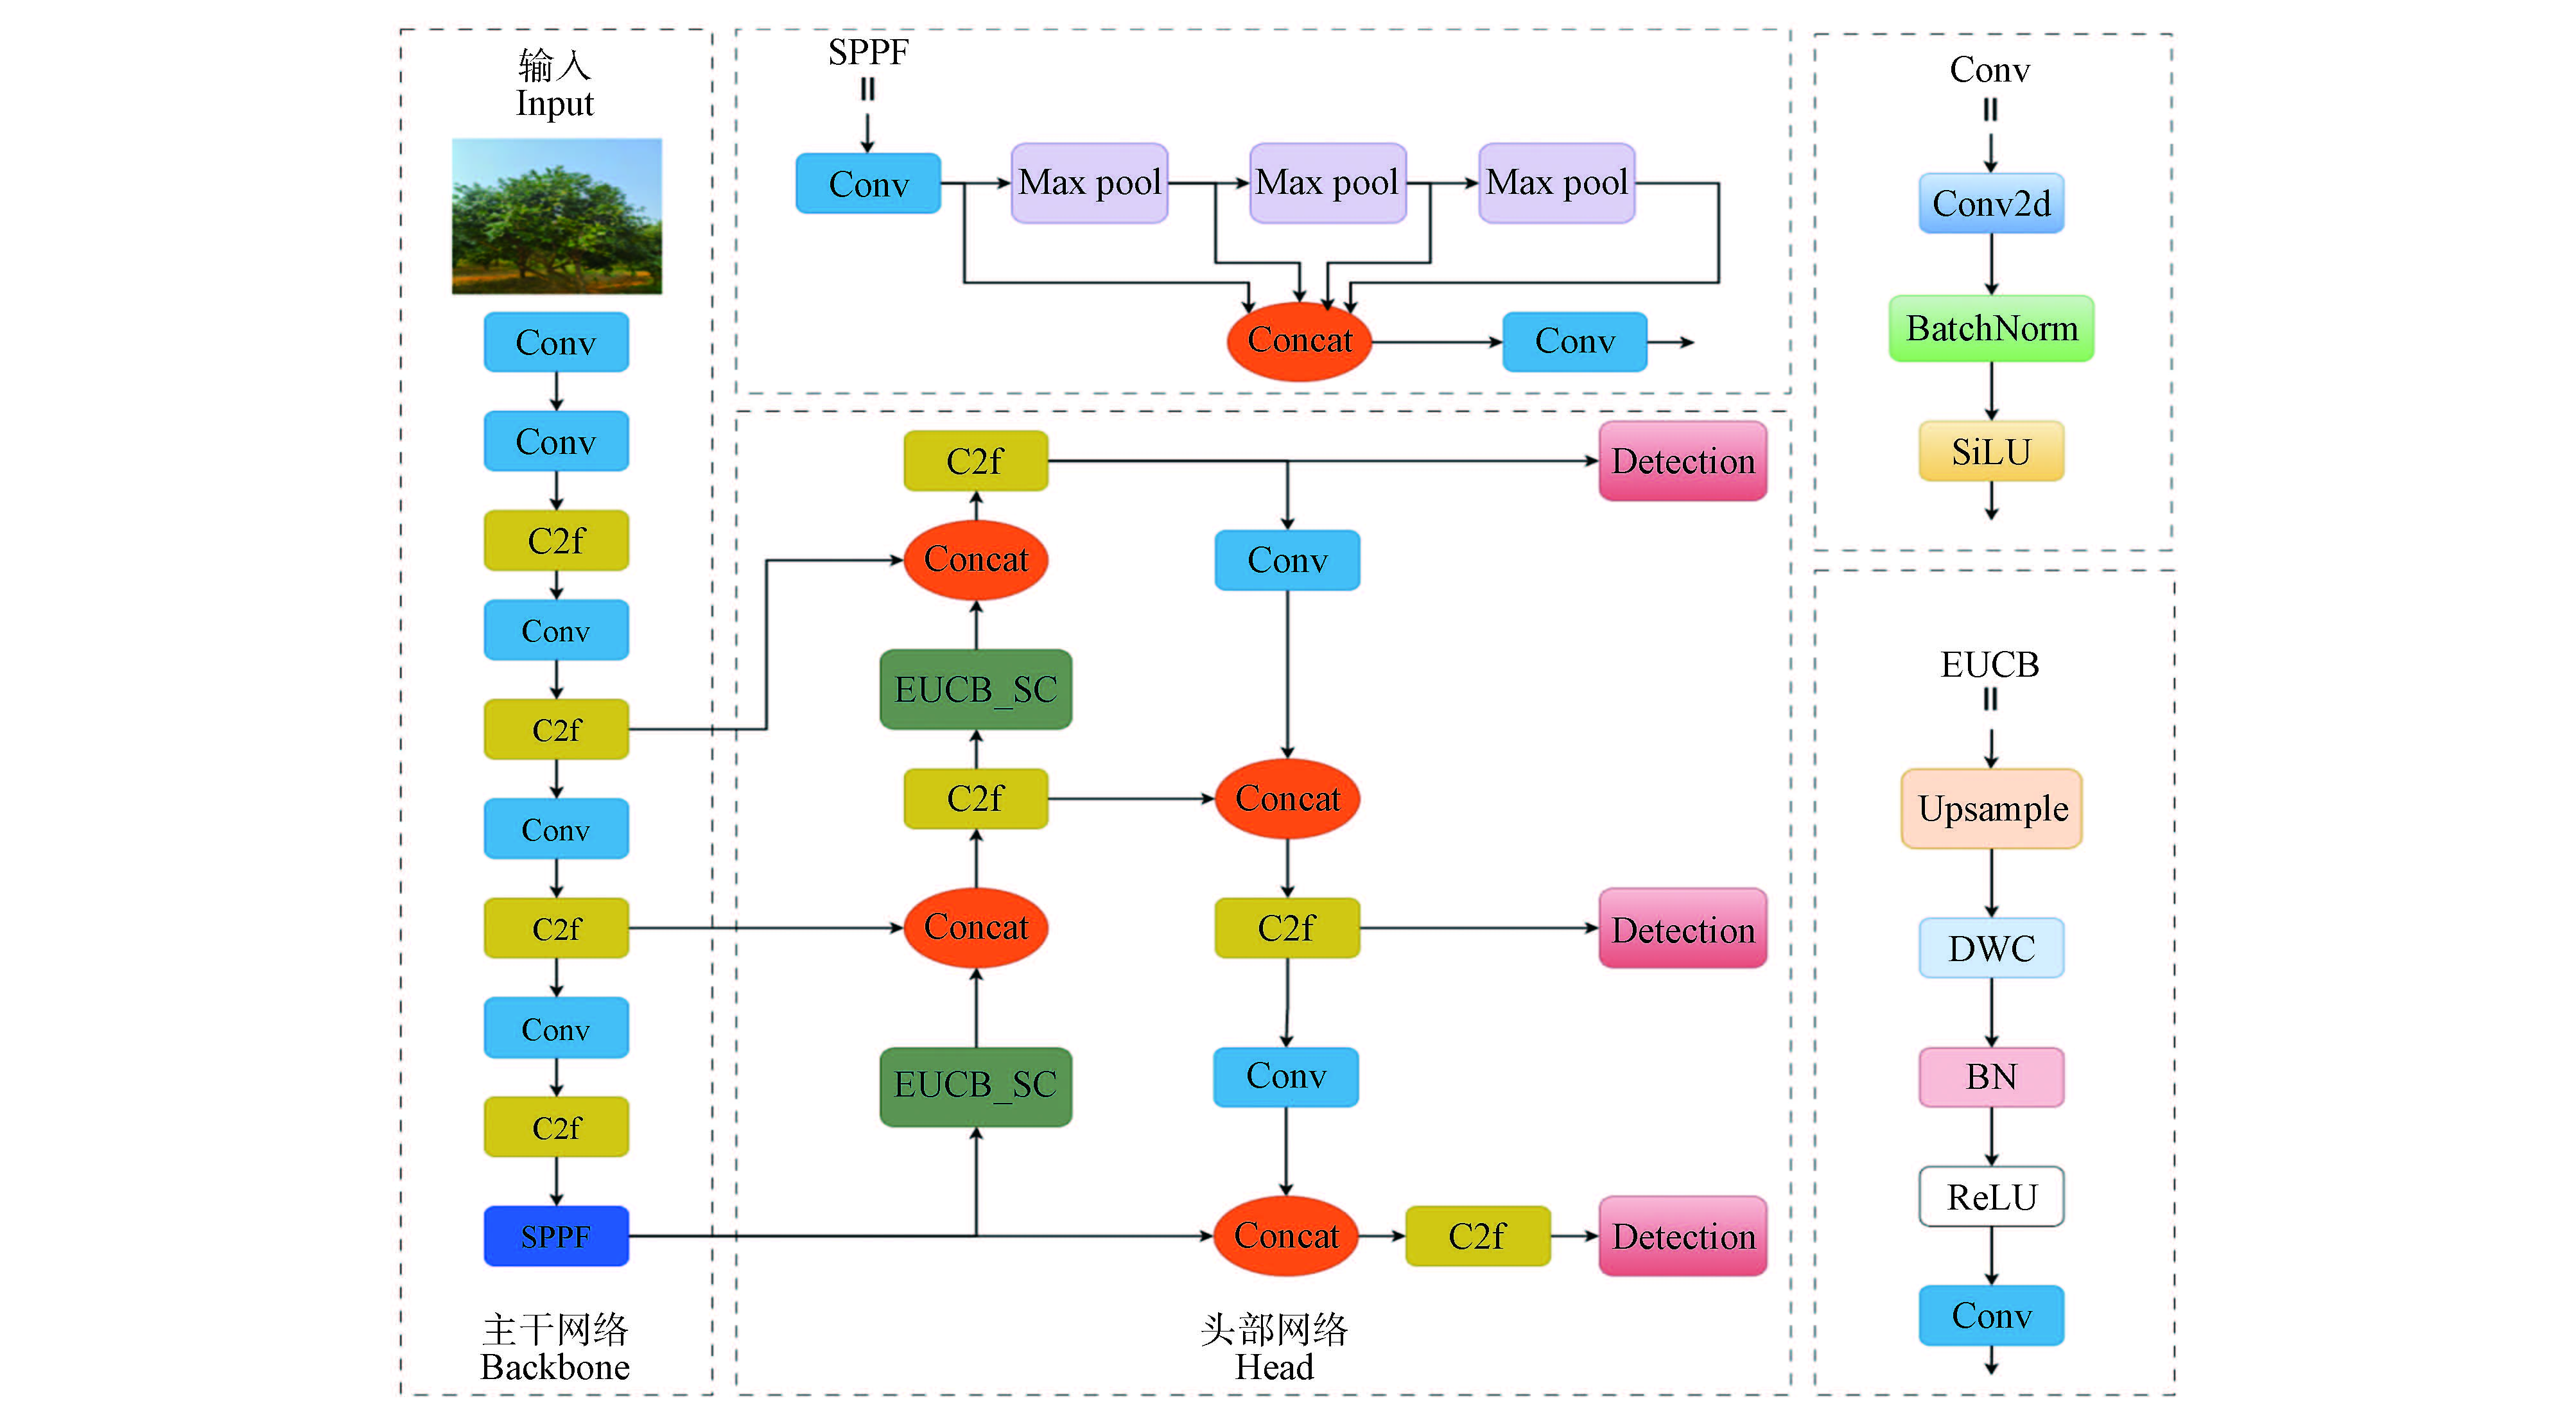
Aiming at the visual perception problem of automatic pruning of Camellia oleifera branches, especially in the outdoor natural environment, branches are vulnerable to wind disturbance, branches and leaves shading and other environmental factors, a visual servo pruning platform based on improved YOLOv8n is designed and developed. The platform is divided into visual inspection system and manipulator pruning system. In the visual inspection system, efficient up-convolution block (EUCB) and multilayer perceptron (MLP) modules are introduced respectively, and EM-YOLO (EUCB and MLP-you only look once) model is designed to improve the feature fusion module and up sampling module, so as to enhance the recognition ability of the model in complex situations. A positioning strategy based on the center point at the bottom of the prediction frame is designed, and the image binarization and skeleton extraction technology are used to predict the pruning posture. The kinematics model of the manipulator is established based on the standard D-H method. The visual servo control strategy is established through the image error to achieve dynamic approximation and attitude self-tuning for the target branch. Compared with the original YOLOv8n, the accuracy, recall and mAP0.5 of EM-YOLO for Camellia oleifera target branches are improved by 0.5%, 7.1% and 3.5%, respectively. The detection performance of EM-YOLO in target branch samples collected under different lighting conditions remain stable. In the indoor automatic pruning experiment, the platform has realized the detection and pruning of the target branches of Camellia oleifera, the recognition success rate is 81.29%, the missing detection rate is 14.03%, the spatial positioning error within the operation range of 1-2 m is less than 1 cm, and the overall pruning success rate of the platform is 80.9%, which can effectively realize the automatic pruning of the target branches of Camellia oleifera, and provide technical reference for the intelligent and standardized management of Camellia oleifera.
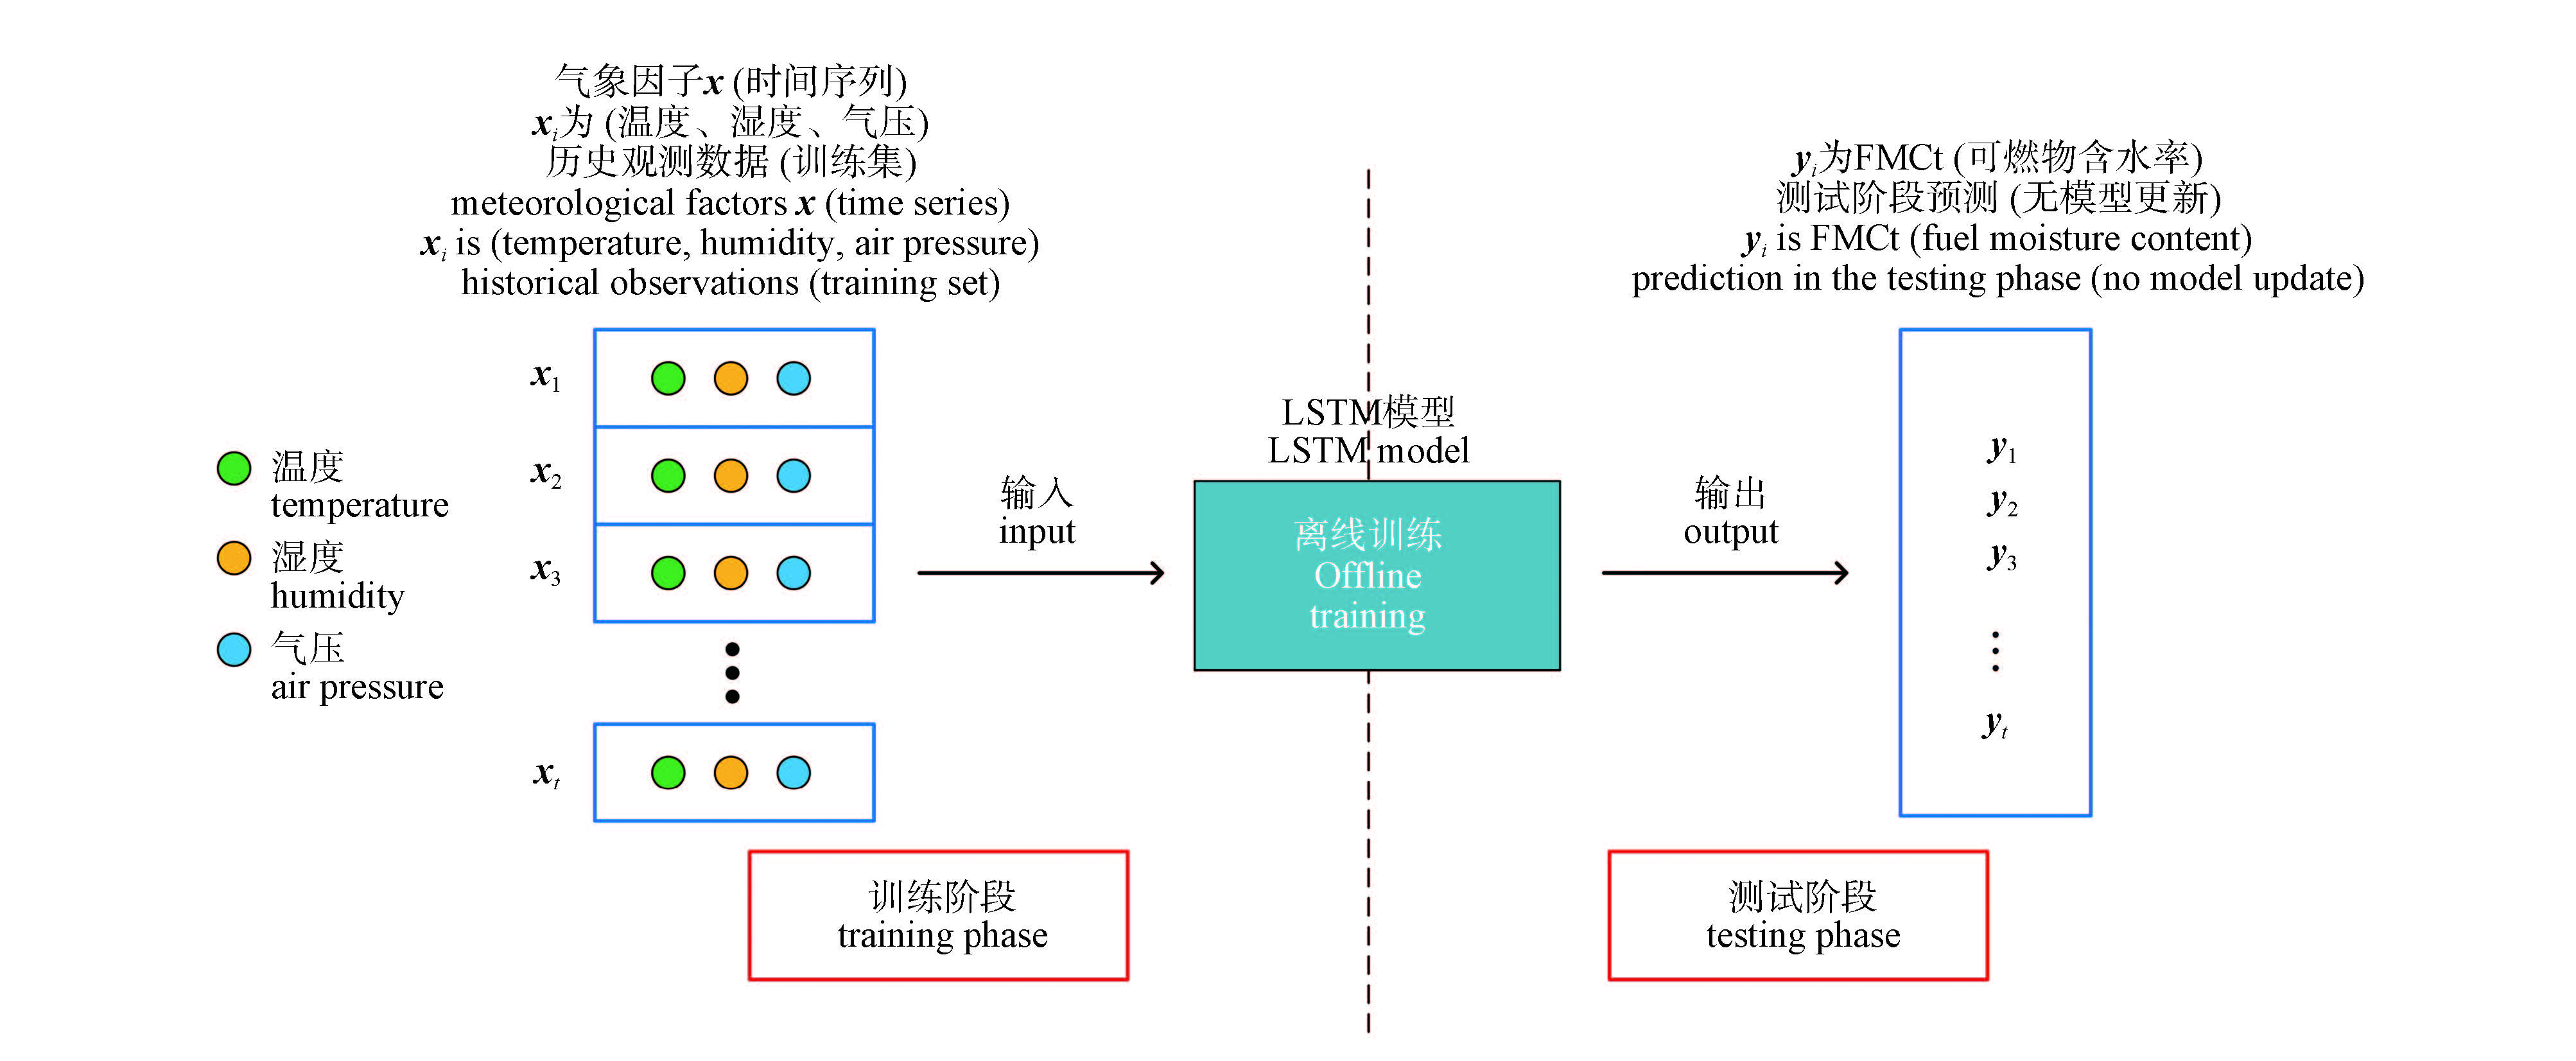
To address the decline in predictive accuracy of existing fuel moisture content models under temporal and cross-species prediction scenarios, an incremental learning-based long short-term memory (LSTM) model is proposed. Taking three typical forest stands—Quercus mongolica, Juglans mandshurica, and Betula platyphylla—at the experimental forest of Northeast Forestry University in Harbin, Heilongjiang Province as study objects, a time-series dataset was constructed using meteorological and moisture content data collected at 20-minute intervals during the high fire-risk period in autumn 2024. The extrapolation performance of the model was evaluated from both temporal and stand-type perspectives. The results showed that, compared with the conventional LSTM model, the proposed method improved prediction accuracy by 46.54% and 47.47% under time extrapolation and cross-species prediction scenarios, respectively, with mean absolute errors (MAE) of 3.61% and 3.97%. In addition, comparisons with a supplementary random forest (RF) baseline model further supported the effectiveness of the proposed approach. The method demonstrates improved adaptability to environmental changes and enhanced predictive capability across different forest stands.
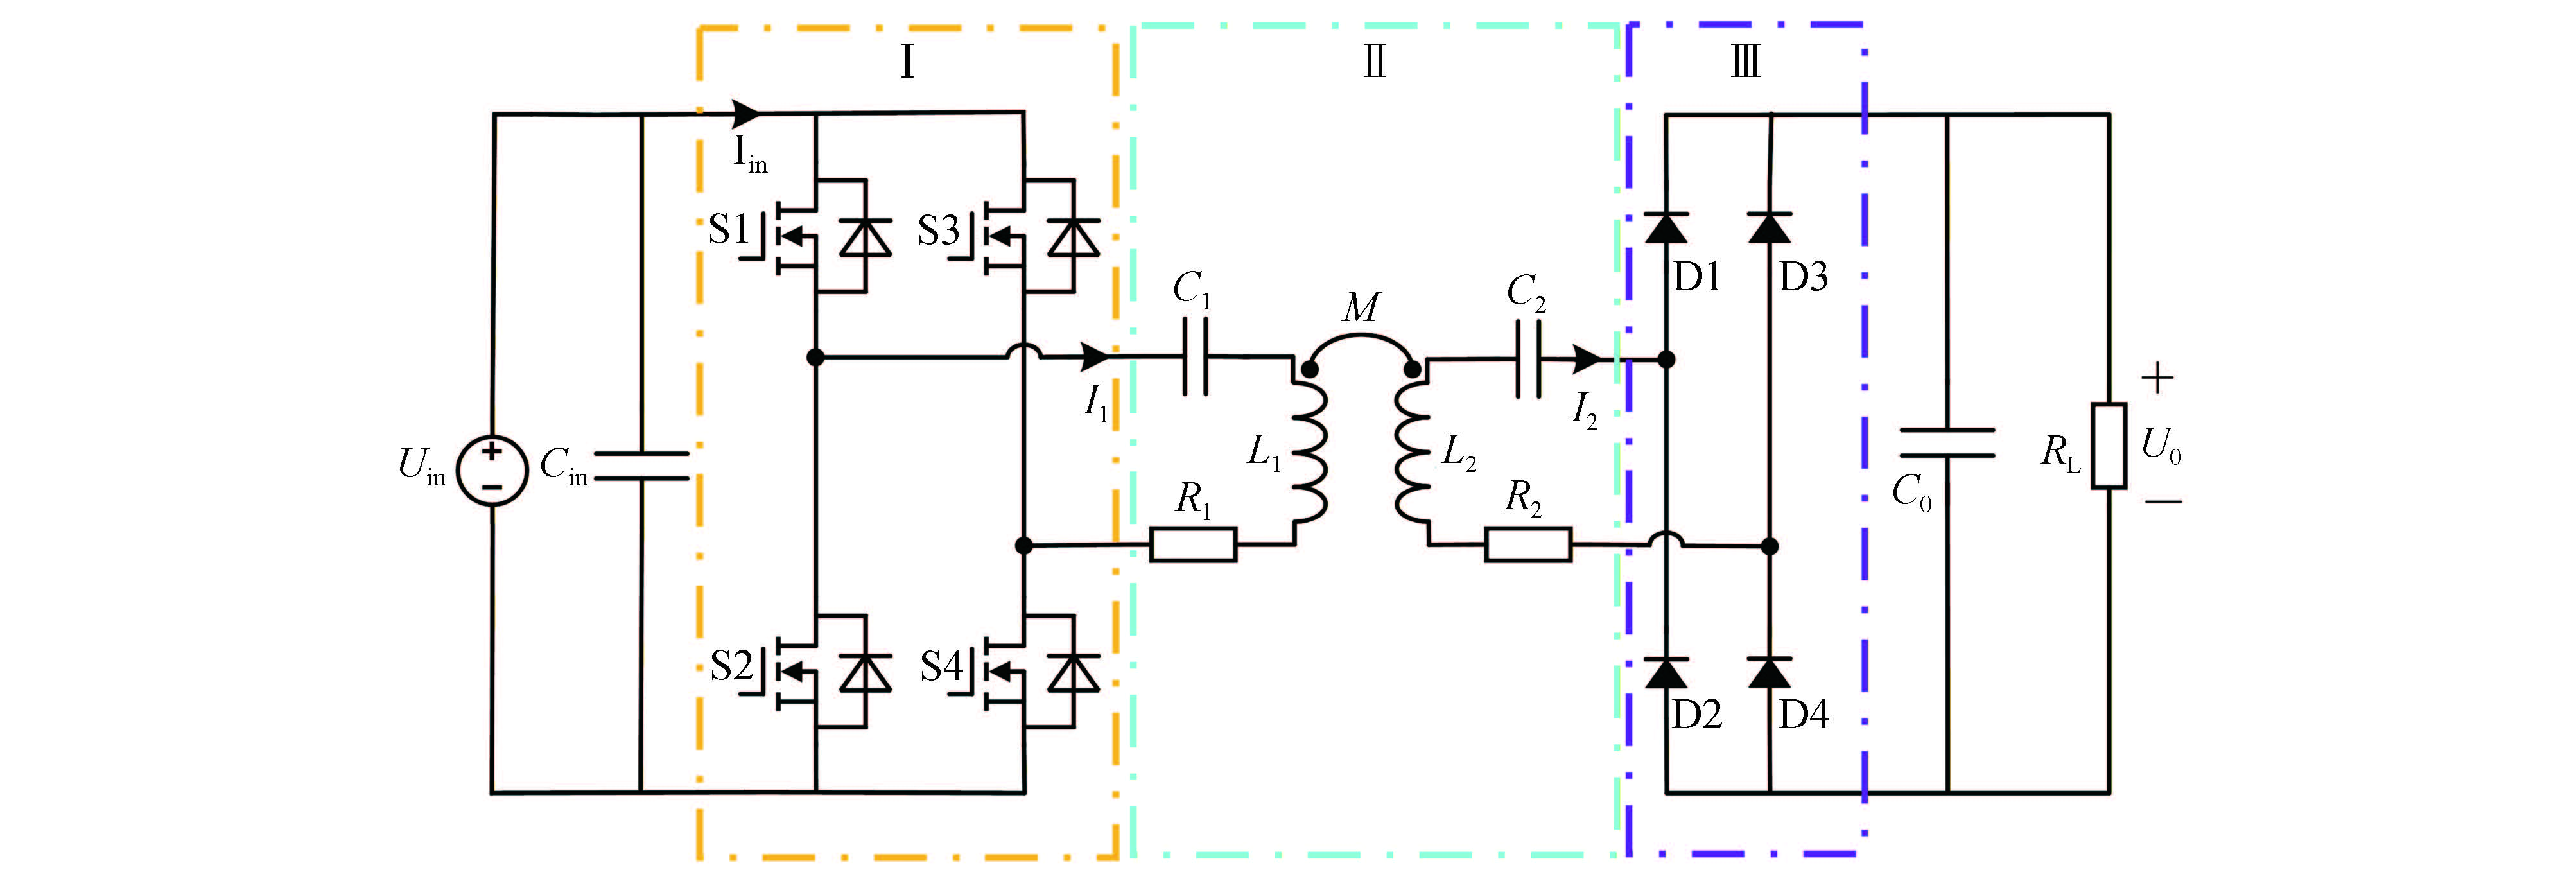
The terrain in forest areas is complex, and the deployment of base stations is restricted. Inspection unmanned aerial vehicles in forest areas generally suffer from “range anxiety”, and the high humidity, dust, and poor heat dissipation conditions in the wild severely restrict the stable operation of wireless charging systems. Therefore, this paper conducts a multiobjective optimization study on the core component parameters of wireless charging systems for inspection unmanned aerial vehicles in forest areas. Firstly, a system equivalent circuit based on the series-series compensation topology is established to reveal the intrinsic relationship between the parameters of the core component-the magnetic coupling mechanism and the transmission efficiency and temperature rise characteristics. Secondly, a CPO-NSGA-Ⅱ (crested porcupine optimizer-non-dominated sorting genetic algorithm Ⅱ) hybrid optimization algorithm is proposed, within the NSGA-Ⅱ (non-dominated sorting genetic algorithm Ⅱ) framework, the dynamic defensive search mechanism of the crested porcupine optimizer (CPO) is introduced to improve the convergence accuracy and global optimization ability of the algorithm. With the core of improving the system’s forest area's adaptability, a multiobjective optimization model that considers transmission capacity, lightweight design, and thermal reliability is established. Training data is obtained through joint electromagnetic-thermal multi-physical simulation to drive the search for the Pareto-optimal solution set. The final experimental prototype tested under actual working conditions in the forest area shows that the system transmission efficiency reaches 89.6%, the maximum temperature after continuous charging for 1 hour is 56.9 ℃, and the wire usage is reduced by 18.2% compared with the optimization before, effectively solving the engineering problems of "heavy, hot, and low efficiency" of the wireless charging system for unmanned aerial vehicles in forest areas.
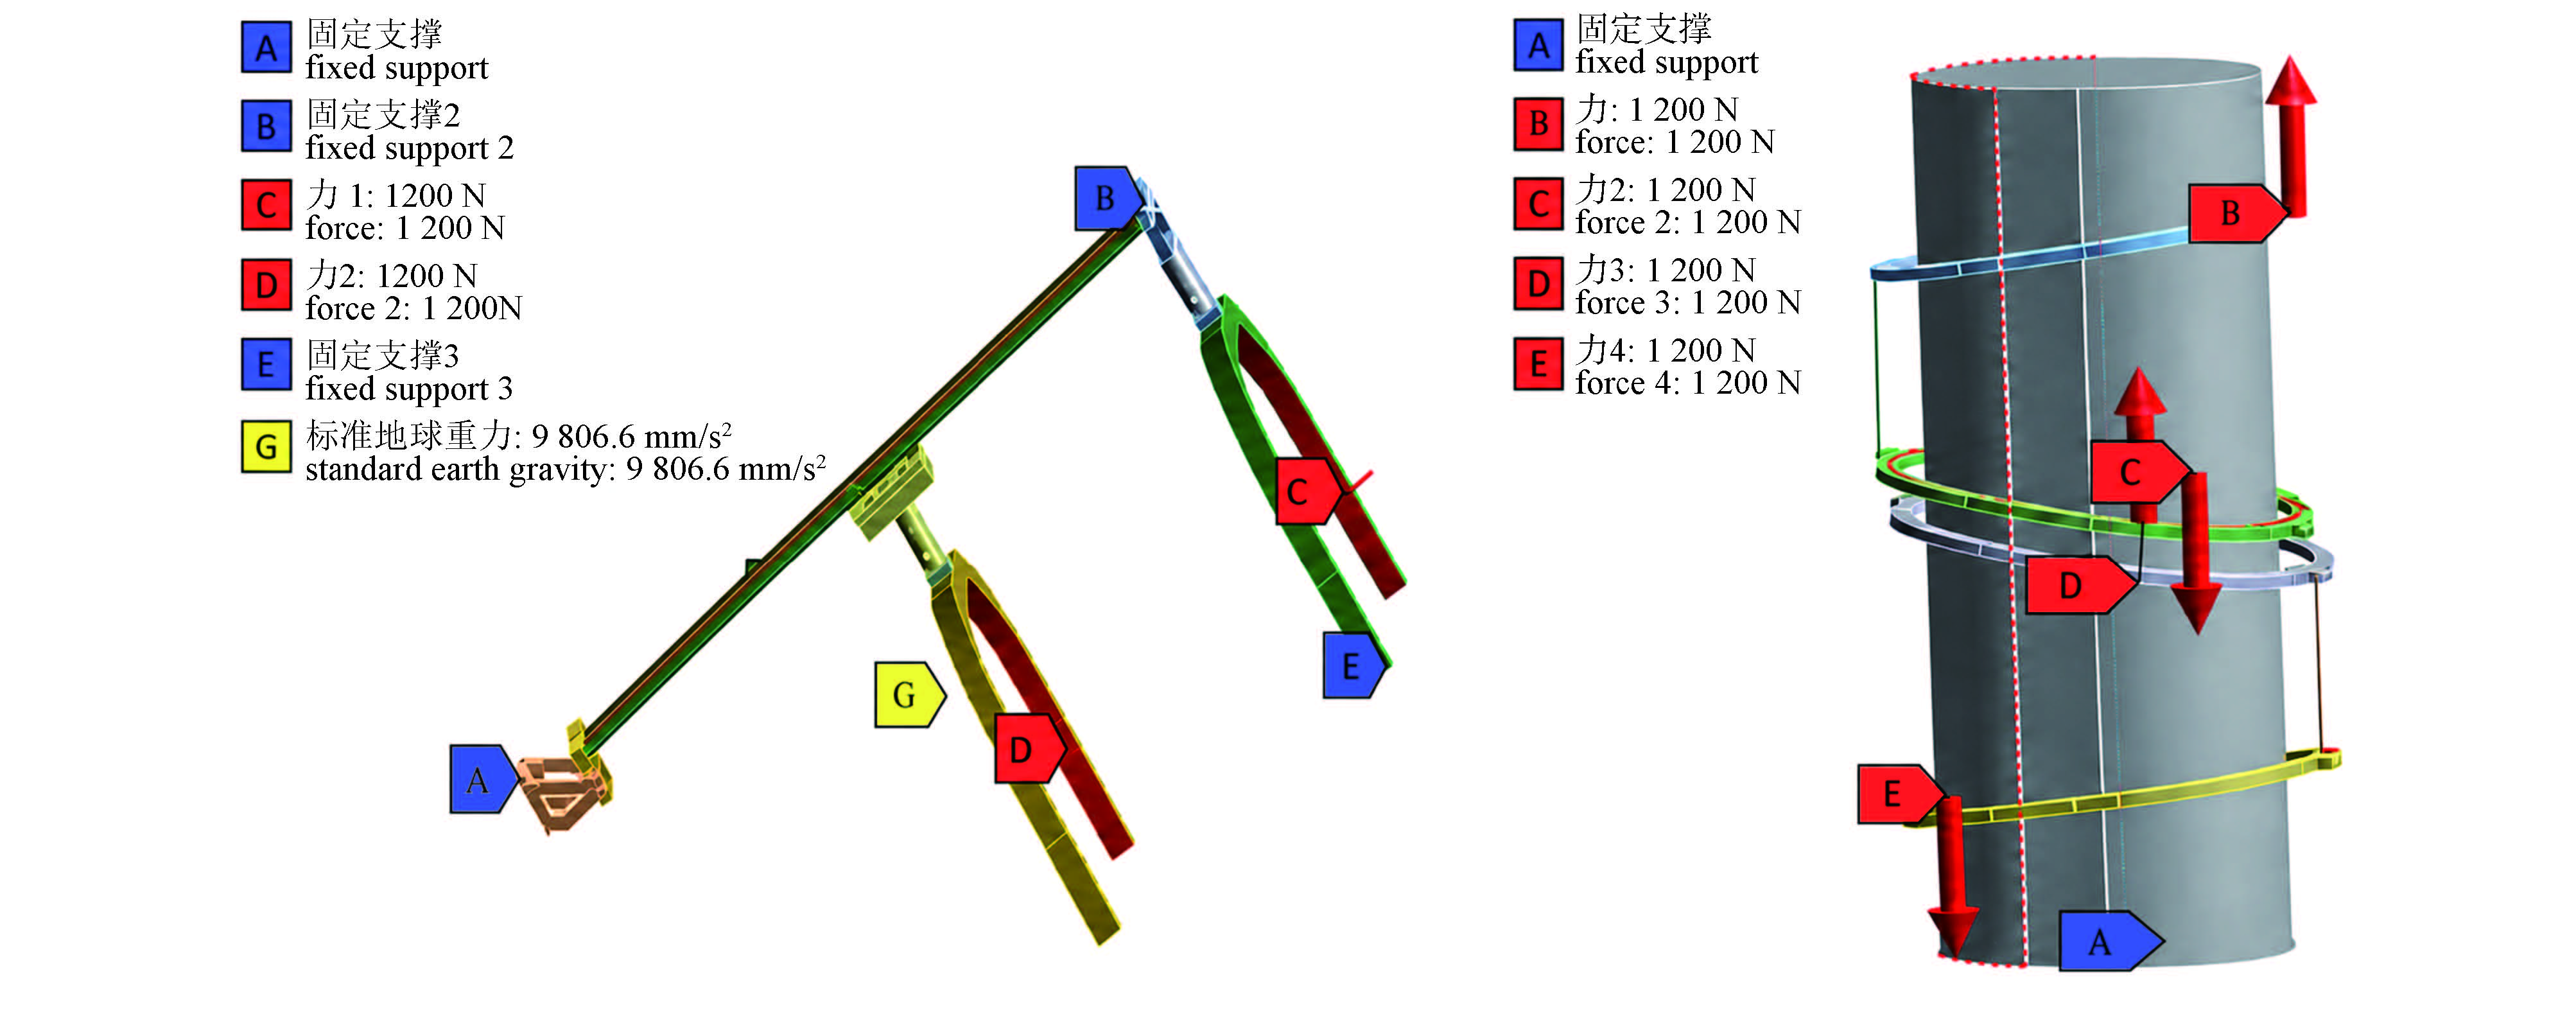
To address the low level of mechanization and the high safety risks associated with manual high-elevation pruning of trees in ecological landscapes, a bionic tree-climbing robot was designed. Inspired by the alternating climbing behavior of primates and the self-locking principle of electrician’s pole-climbing devices, an overall configuration integrating dual-ring clamping, lead-screw-driven extension, and chain-saw pruning was proposed to achieve trunk gripping, inchworm-type climbing, and lateral branch pruning. A three-dimensional model of the robot was developed using unigraphics NX (UG). The displacement, clamp contact force, and drive-motor output responses during the climbing process were investigated through dynamic simulations using the automatic dynamic analysis of mechanical systems (ADAMS). Finite element reliability analyses of the tree-holding clamp, lead screw, and connecting components were conducted using ANSYS workbench. In addition, a hierarchical control system integrating a programmable logic controller (PLC) and a host computer was established. A pressure-feedback module was incorporated to detect the clamp tightening state and coordinate the climbing motions. The simulation and analysis results showed that the robot could continuously climb according to the predefined inchworm-type gait, with a climbing distance of approximately 150 mm per cycle and no evident overall downward slippage during operation. During the stable climbing stage, the contact force between the tree-holding clamp and the tree trunk was approximately 960 N, satisfying the requirements for vertical climbing, stationary holding, and self-locking. Finite element analysis indicated that the maximum stress of the tree-holding clamp was approximately 46 MPa, which was lower than the yield strength of Q235 steel of 235 MPa, corresponding to a safety factor of 5.08. No excessive deformation was observed in the key load-bearing components. The control system coordinated three stepper motors to complete the opening and closing of the clamps and the extension and retraction of the lead screw, while ensuring that at least one set of clamps remained engaged during both climbing and descending operations. The proposed robot has a feasible structural configuration, can perform inchworm-type climbing according to the predefined gait, and meets the strength requirements of its key components. The design provides a reference for the miniaturization and automation of tree-pruning equipment used in ecological landscapes.